SJSU CyberAI Summer Camp · June 22, 2026
Curiosity, Passion,
and Learning to Learn

Matthias Müller
A journey from Lego to OpenBot.

The Foundation
Logic meets the physical world

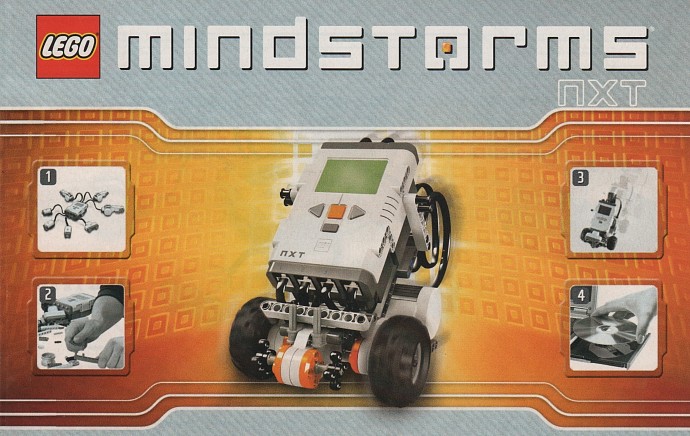
Lego Mindstorms was my first real introduction to robotics. The realisation that logic could control physical things changed everything.

Lego Mindstorms
The Foundation
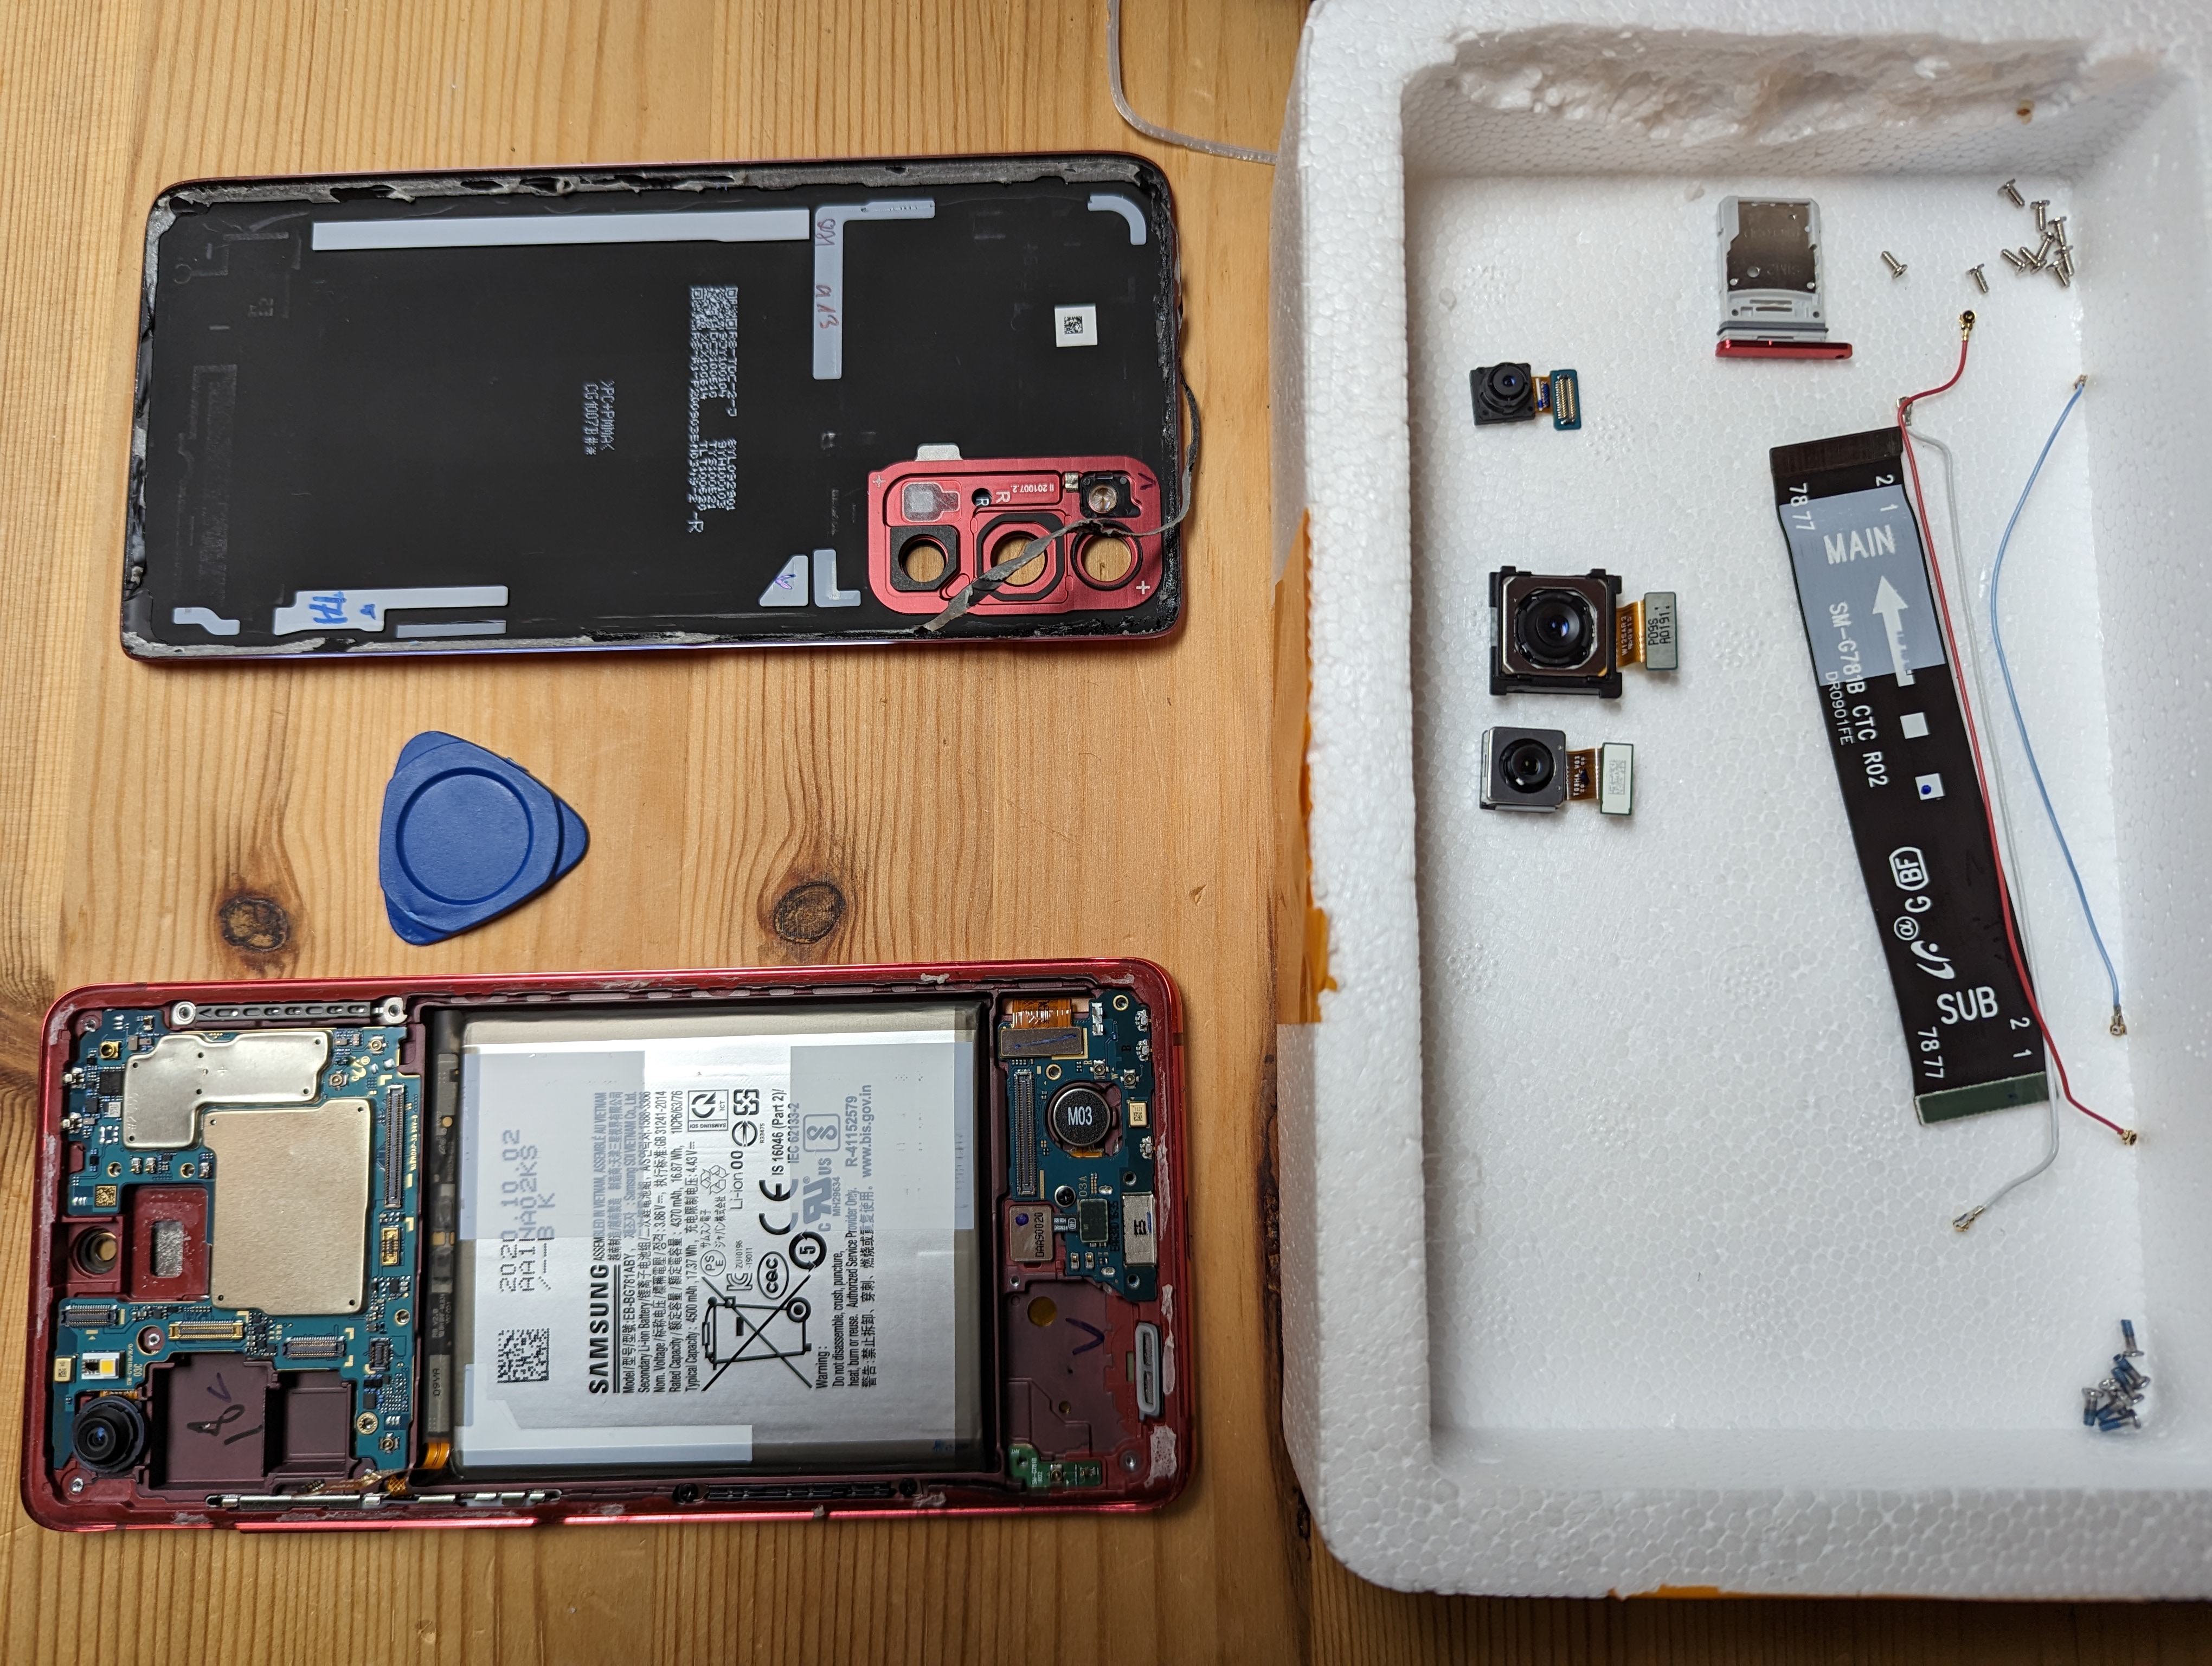
Taking things apart

I've been fixing electronics since I was a kid — opening things up just to see how they worked. That instinct was the seed of everything.

phone teardown
The Skills Behind the Projects
Every project I built was preparing me for the next.

The skills didn't come from a curriculum.
They compounded, one project at a time.

Lego Mindstorms
→
Electronics / Tinkering
→
Soldering
→
3D Printing
→
Custom Drones
The Expected Path
Meanwhile, I followed the expected path.
🎓
B.Sc. Electrical Engineering
The degree everyone said to get.
💍
Got Married
The milestone everyone expected next.
💼
Started Working in Industry
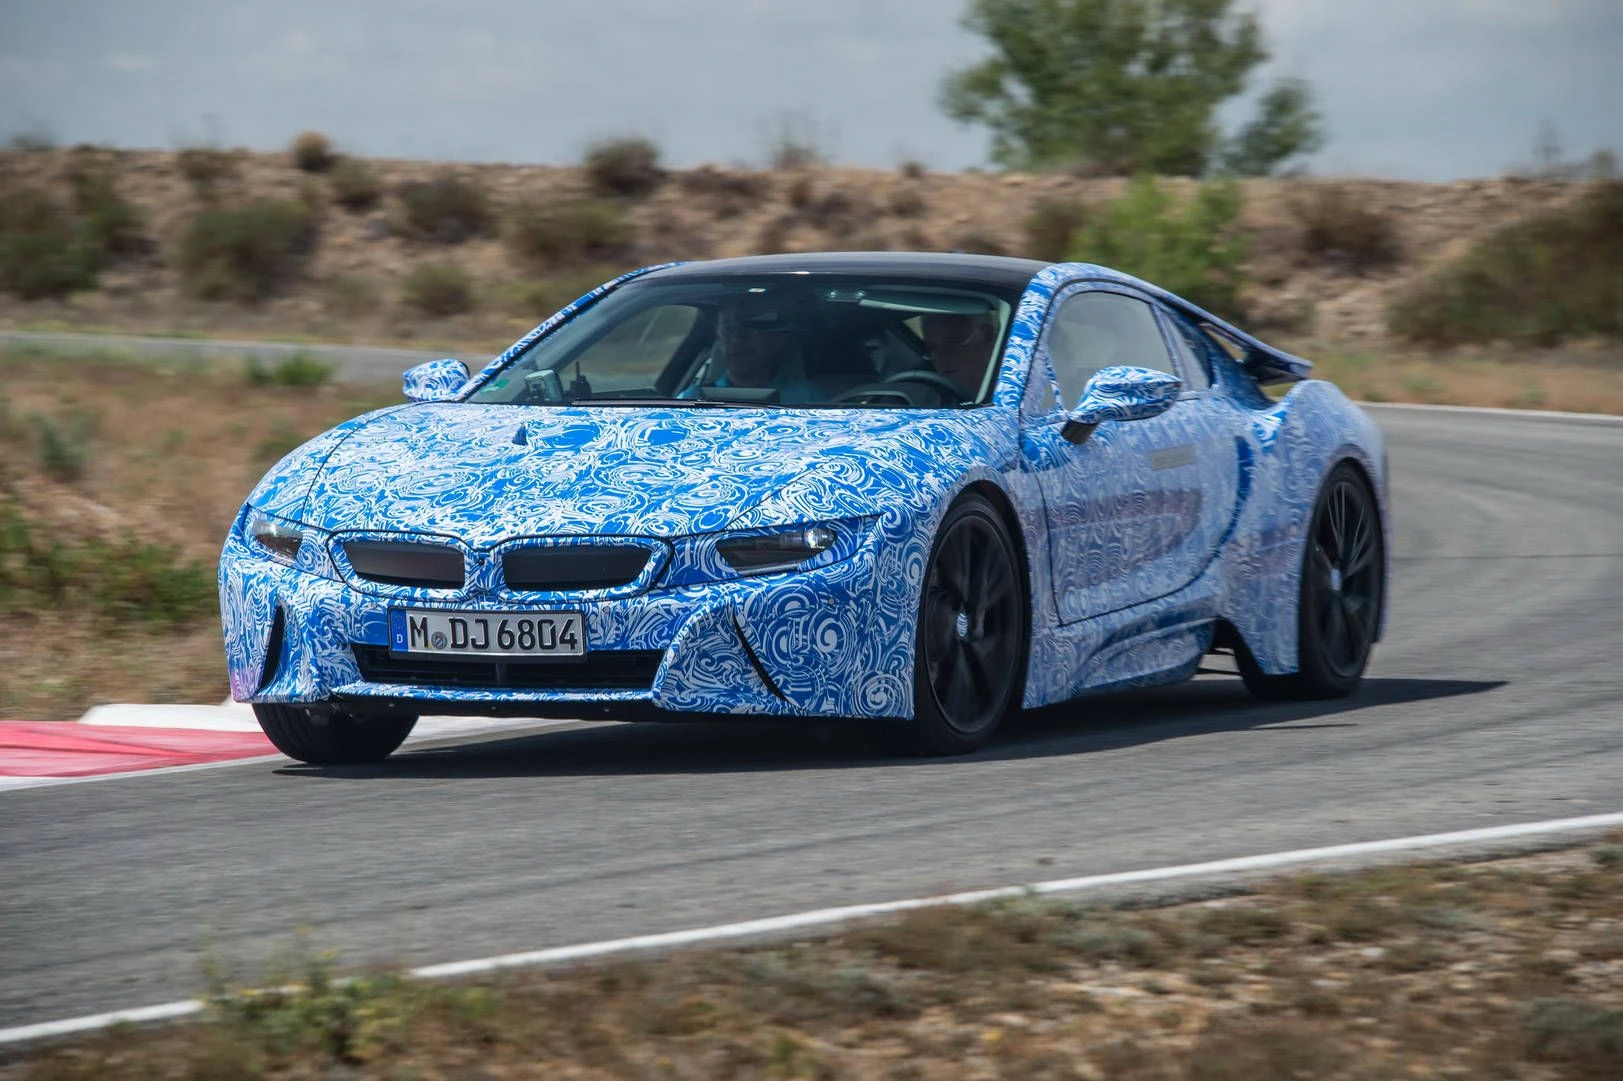
A real job at BMW. Stable. Predictable.

Nothing wrong with that.
But the curiosity didn't stop.
The side projects were just getting started.

BMW i8 prototype
BMW
The dream job.
The Work
Developing mild-hybrid alternators — now in most cars on the road. Test driving early prototypes like the BMW i8.
The Catch
But the basement called every weekend.
Starting Over
I quit.

BMW felt like the void. So I left — driven by instinct, not comfort. Managing suppliers wasn't why I studied engineering.

Decision 1
Left BMW
Desiring hands-on work over project management.
Then I started over.
↓
Decision 2
MS in EE Communications
Theoretical. Not applied. Still not quite right.

Started a Master's in Electrical Engineering, focused on communications theory. But it was not a great fit, and the next decision only took a few months.

↓
Decision 3
Changed Topic & Adviser
Computer Vision. Building. Following the passion.
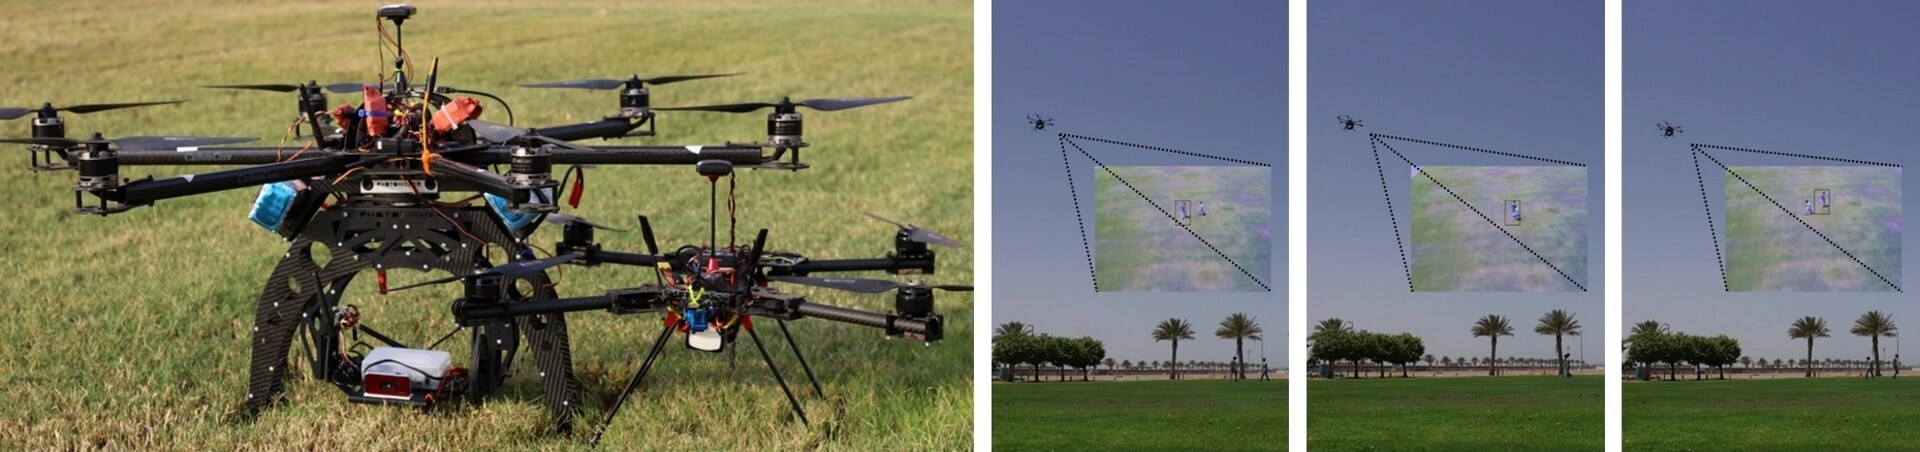
PhD
Computer vision for drones.

Object detection, tracking, drone autonomy.
Hobby and research were converging on the same thing: getting algorithms to work on real hardware.

PAT drone research
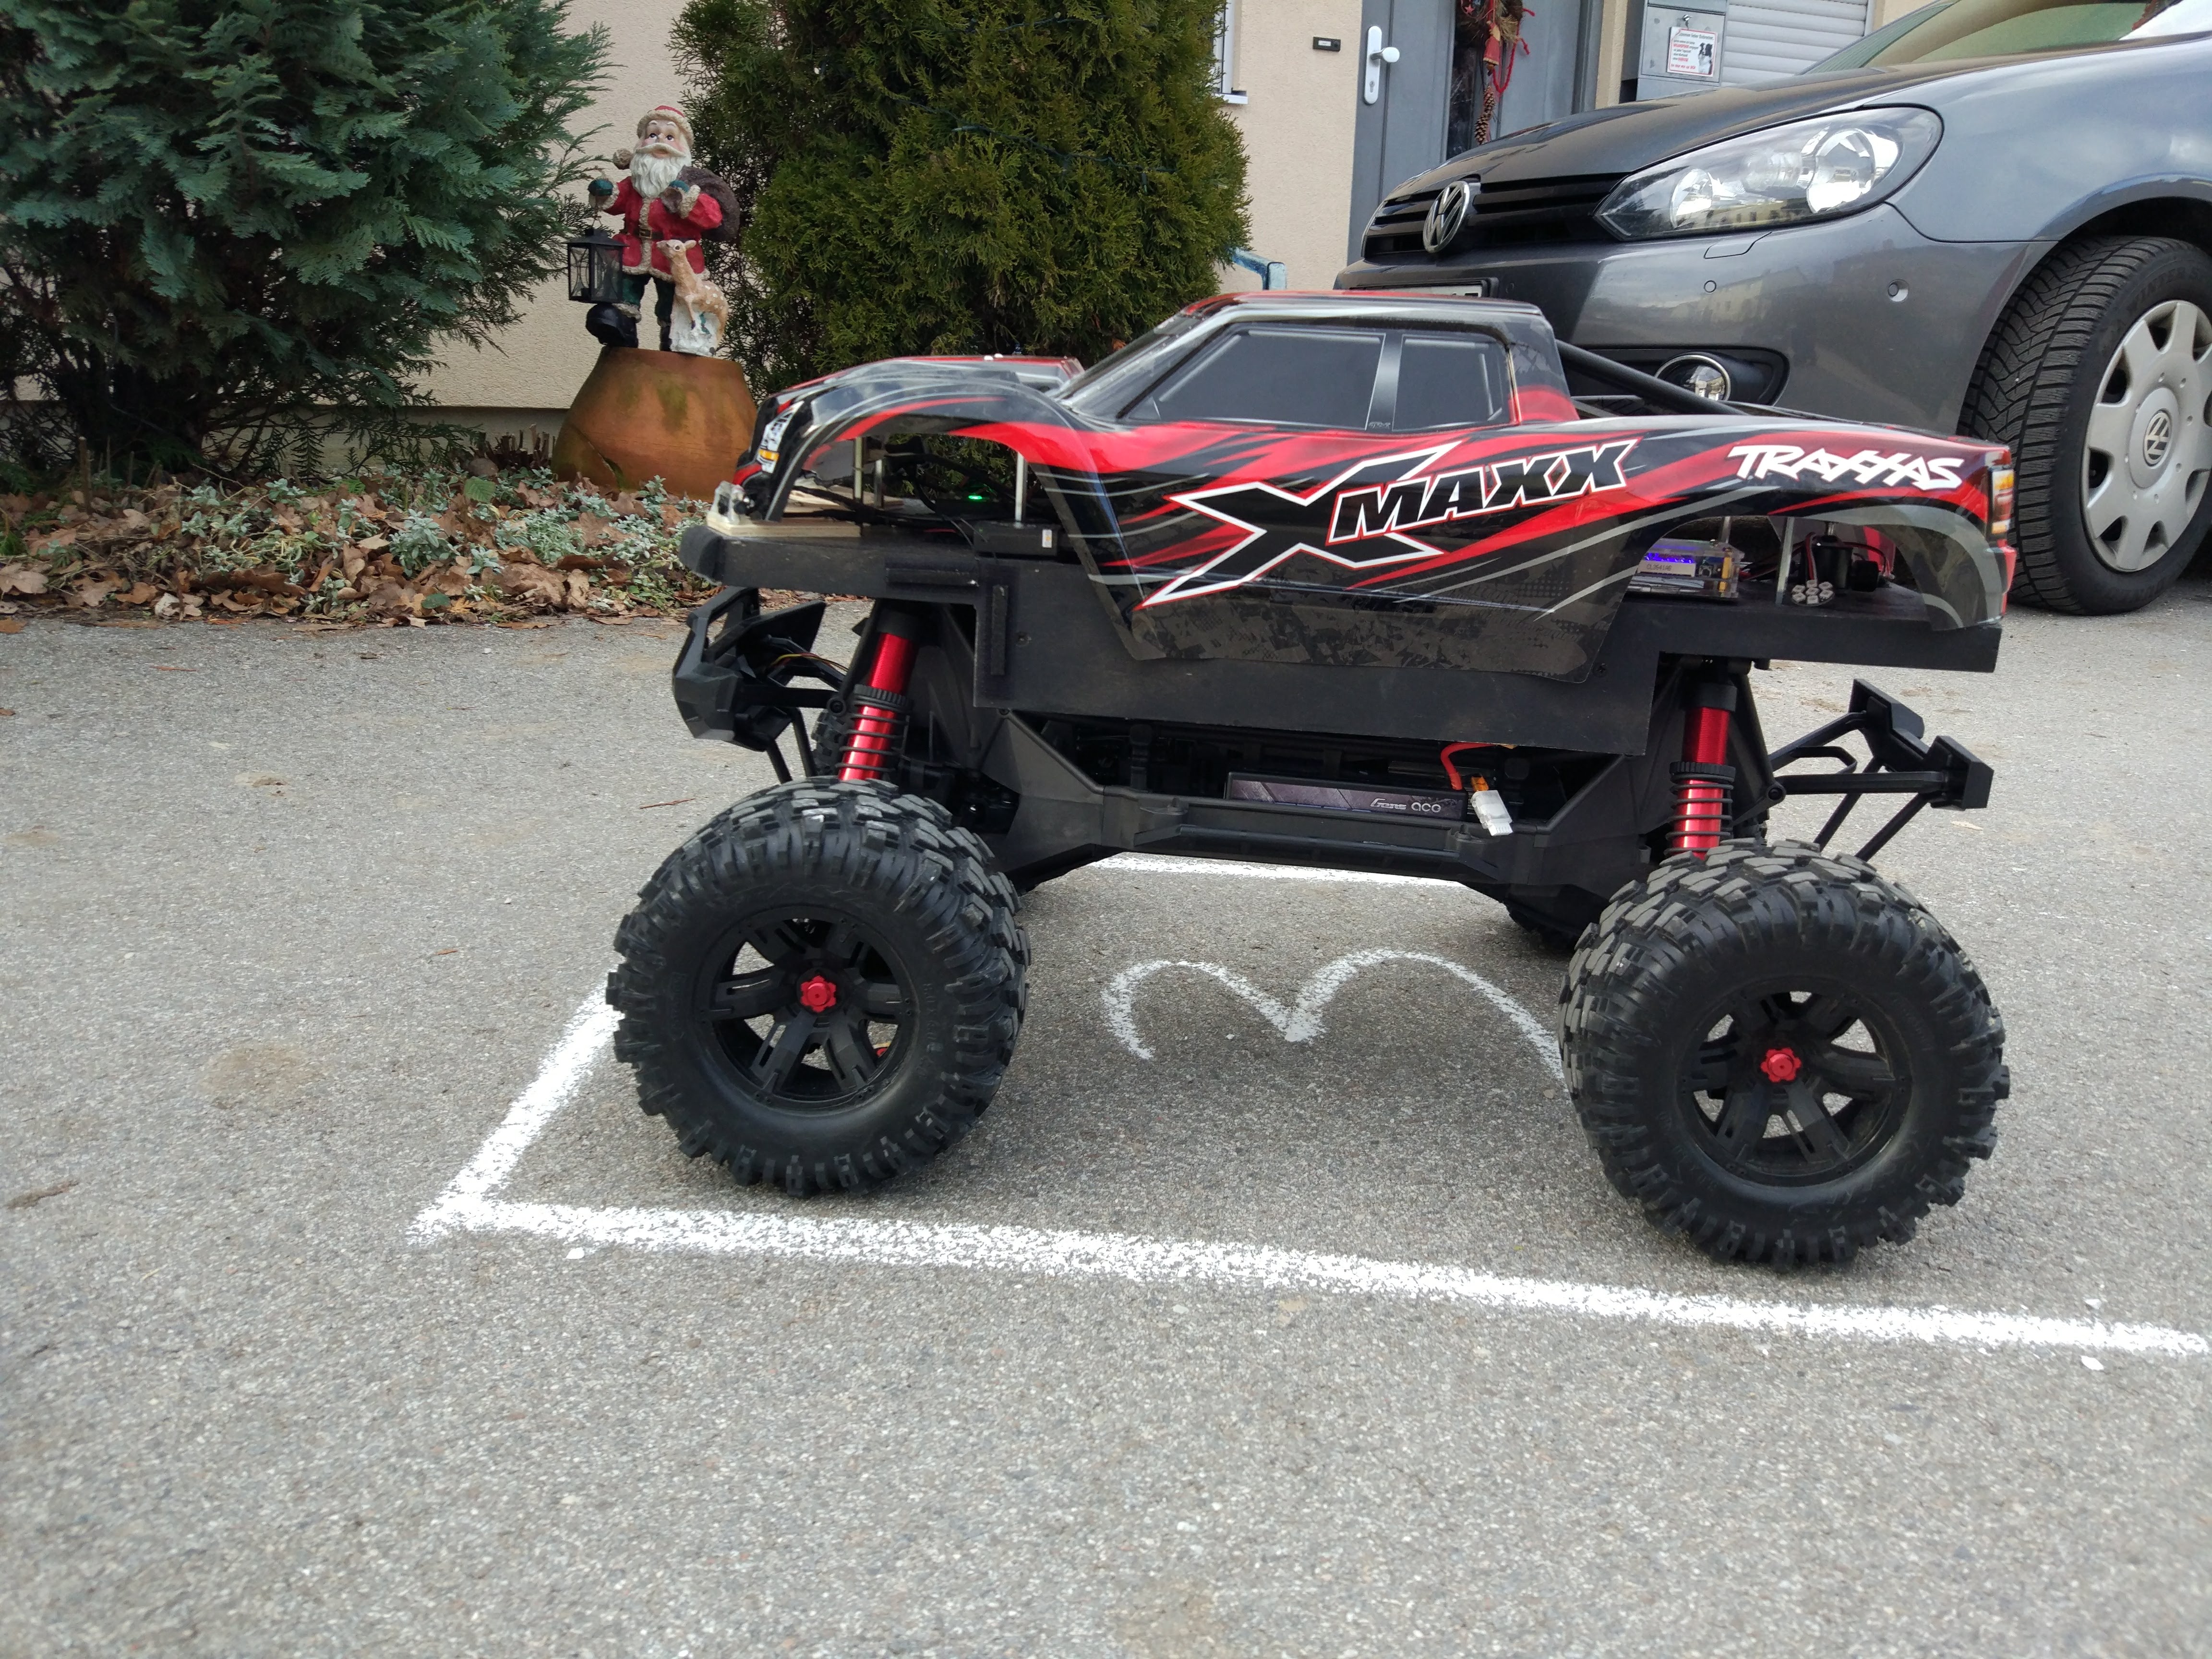
First autonomous driving project
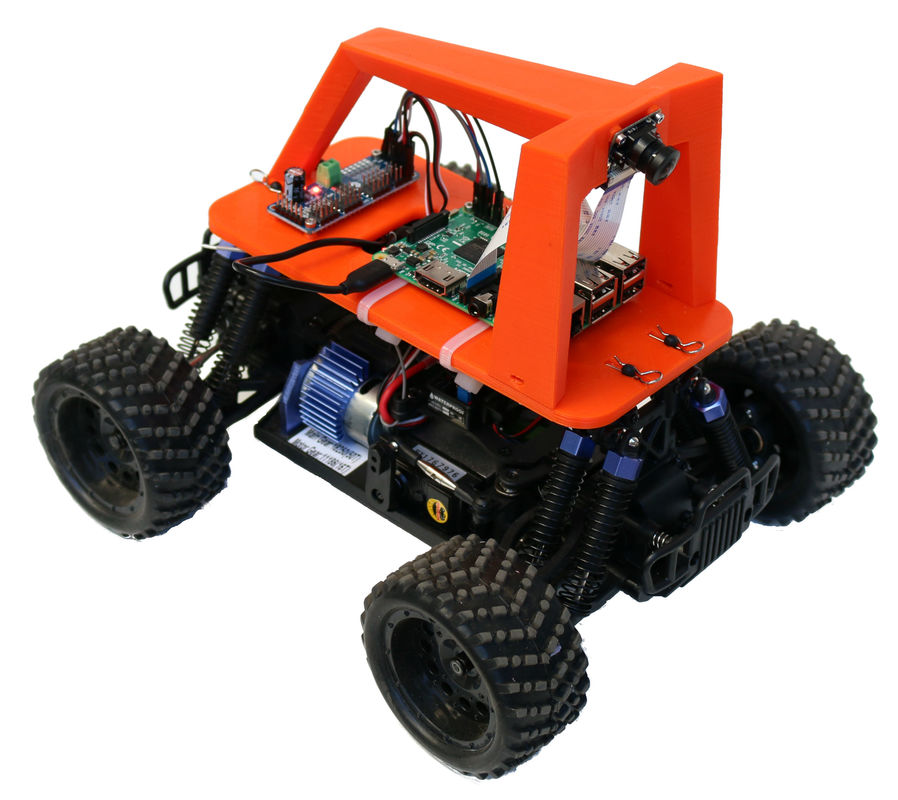
A 1:5 scale self-driving RC truck.

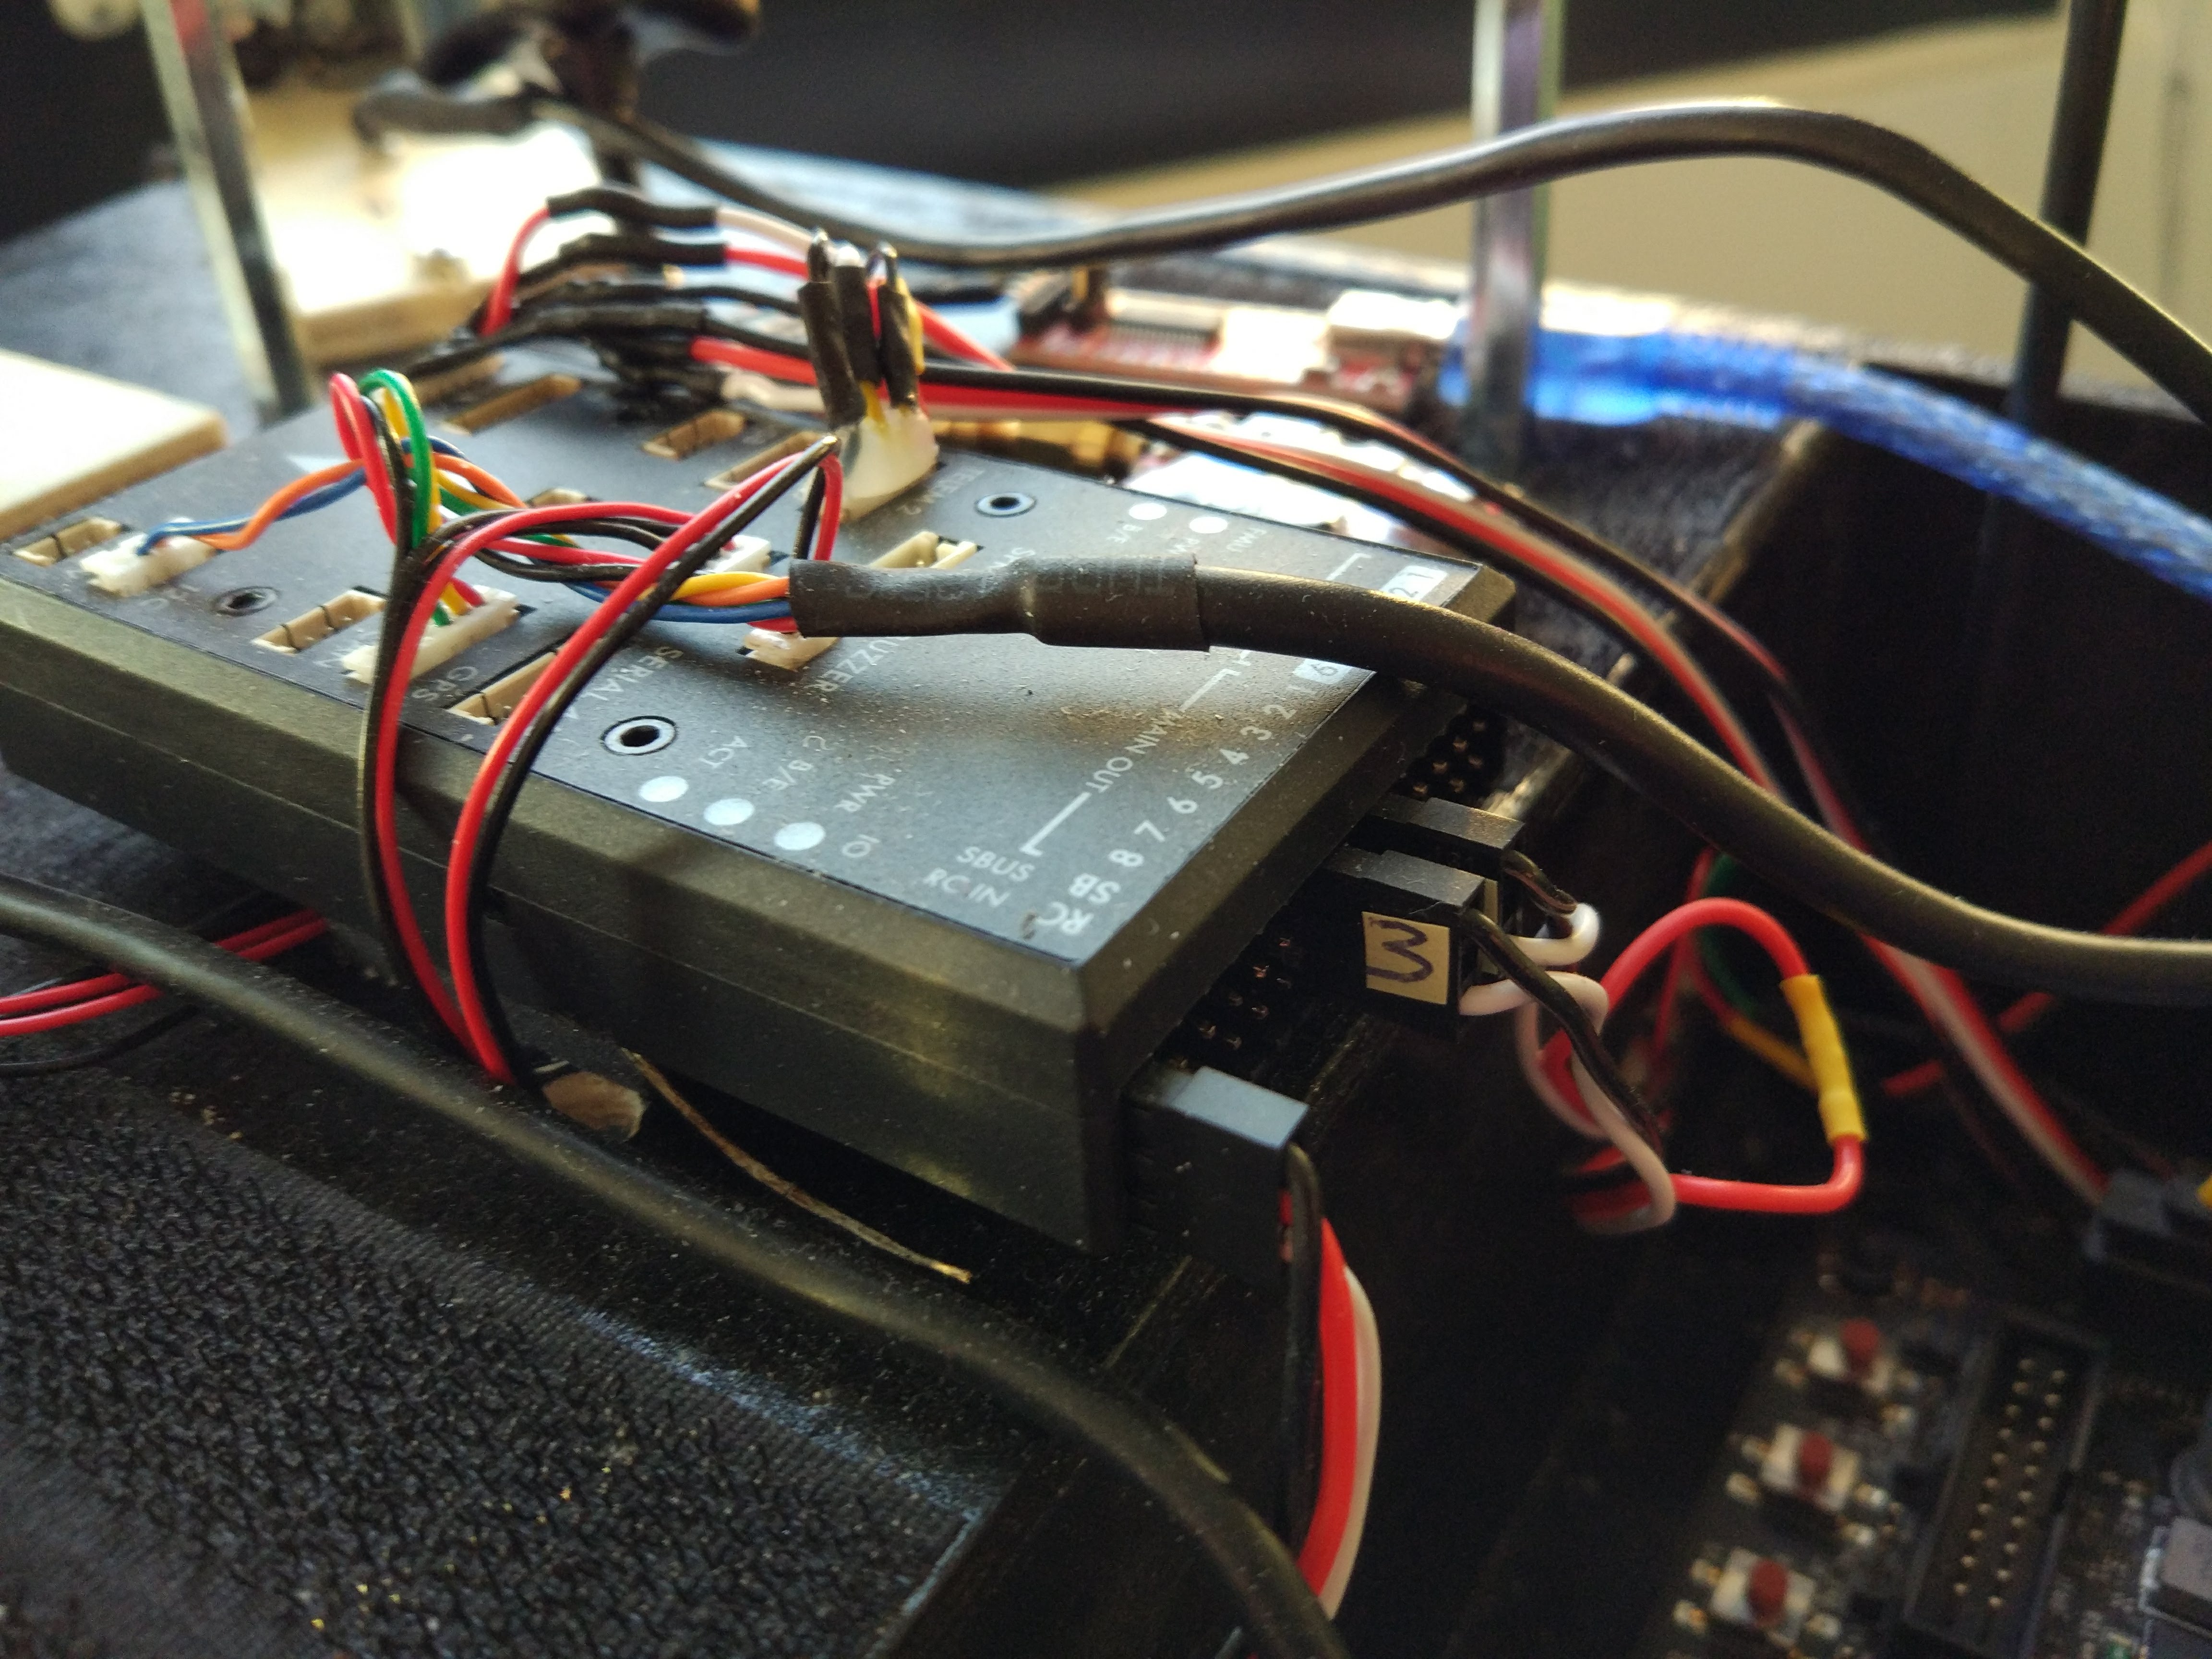
Built during a research internship — retrofit a 1:5 scale RC truck with cameras and sensors, then teach it to drive itself.

This is where everything starts.

RC truck exterior
RC truck electronics
ICRA 2018
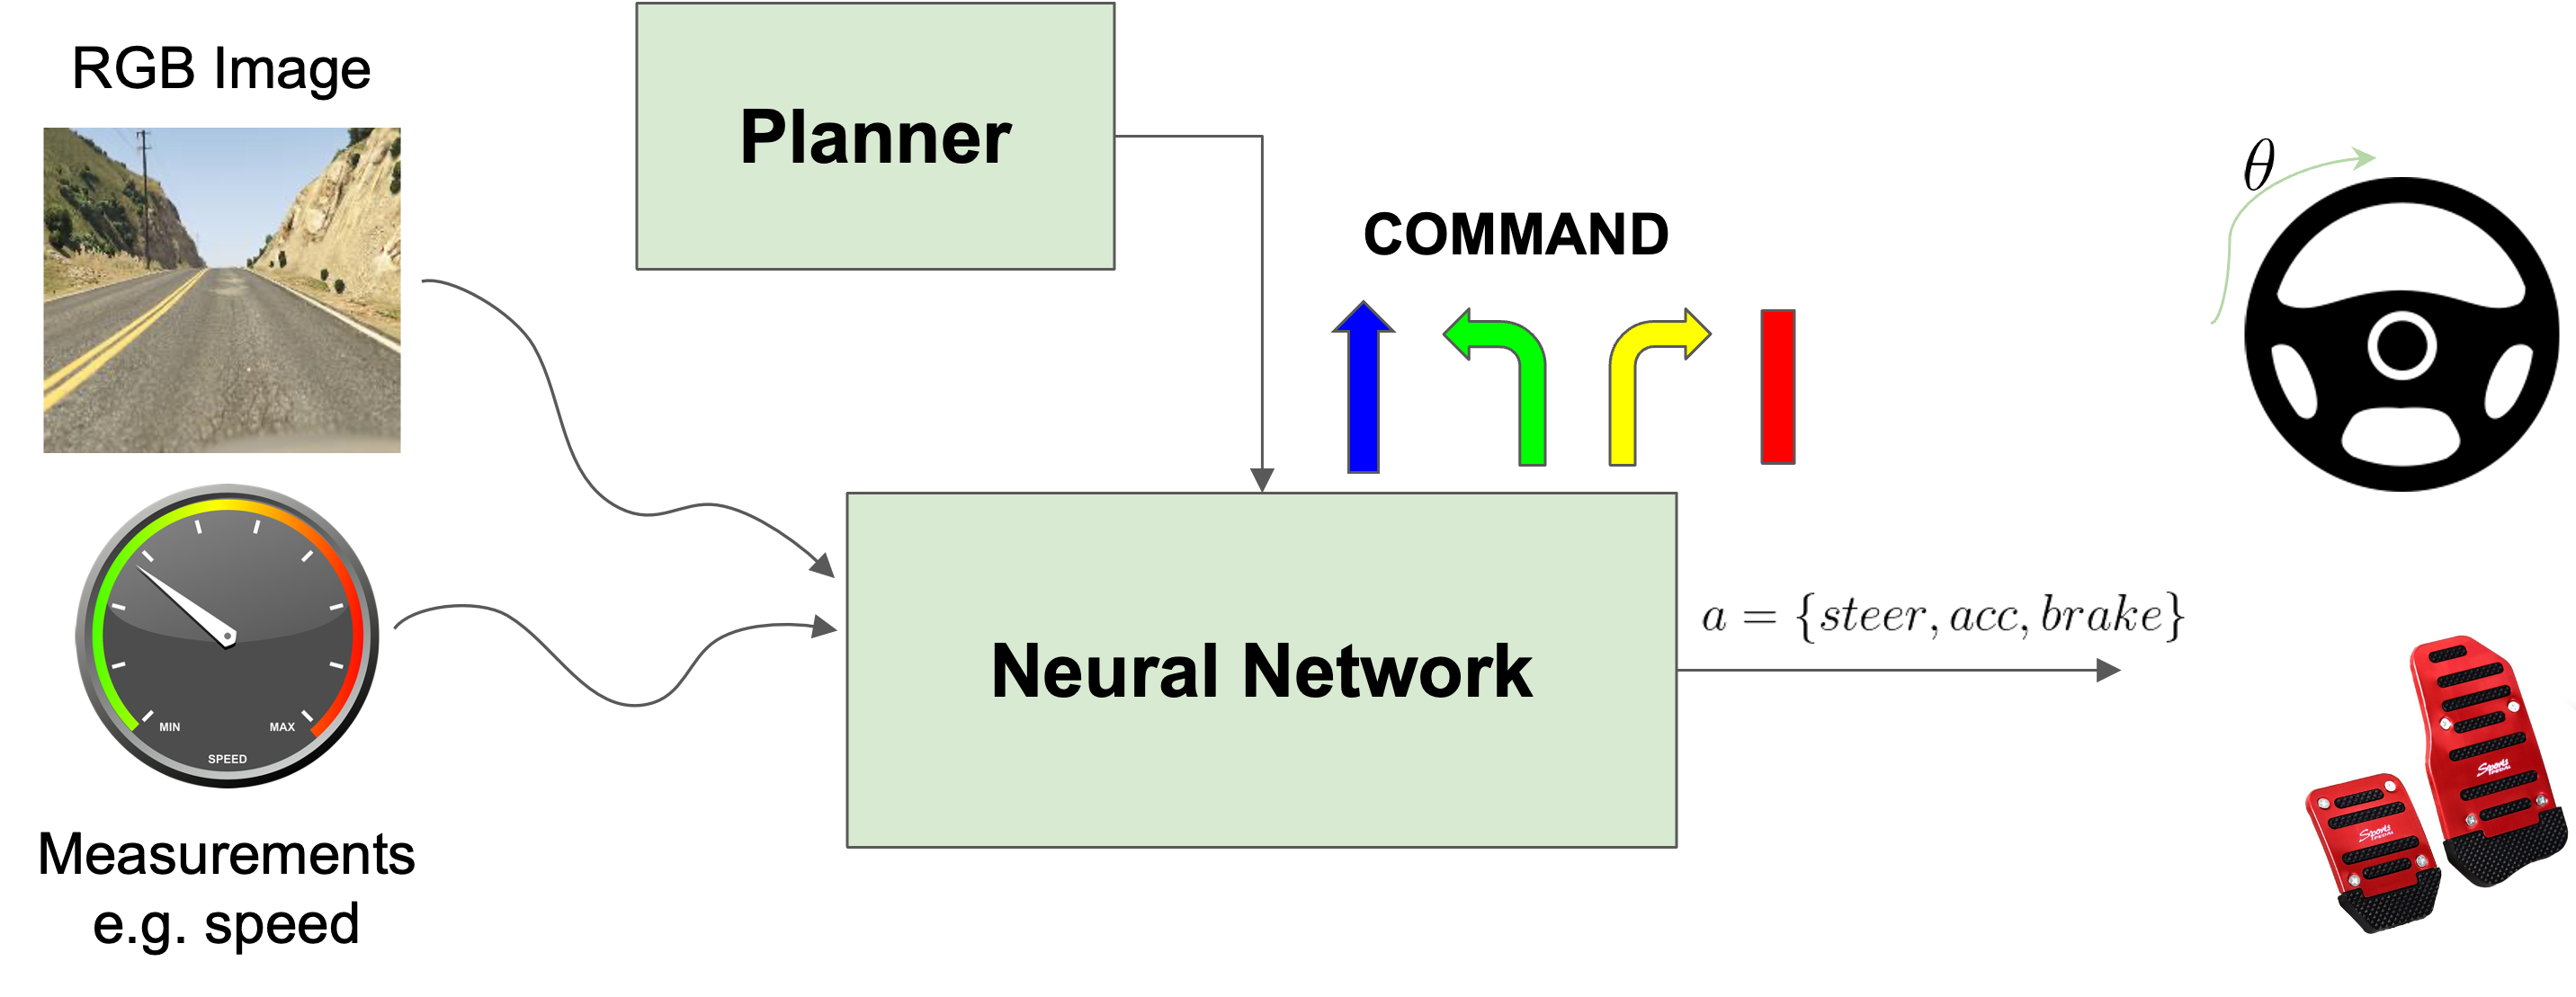
Conditional Imitation Learning
CIL architecture: RGB image + speed measurement + planner command → neural network → steering and pedals

We taught this truck to drive using human demonstrations.

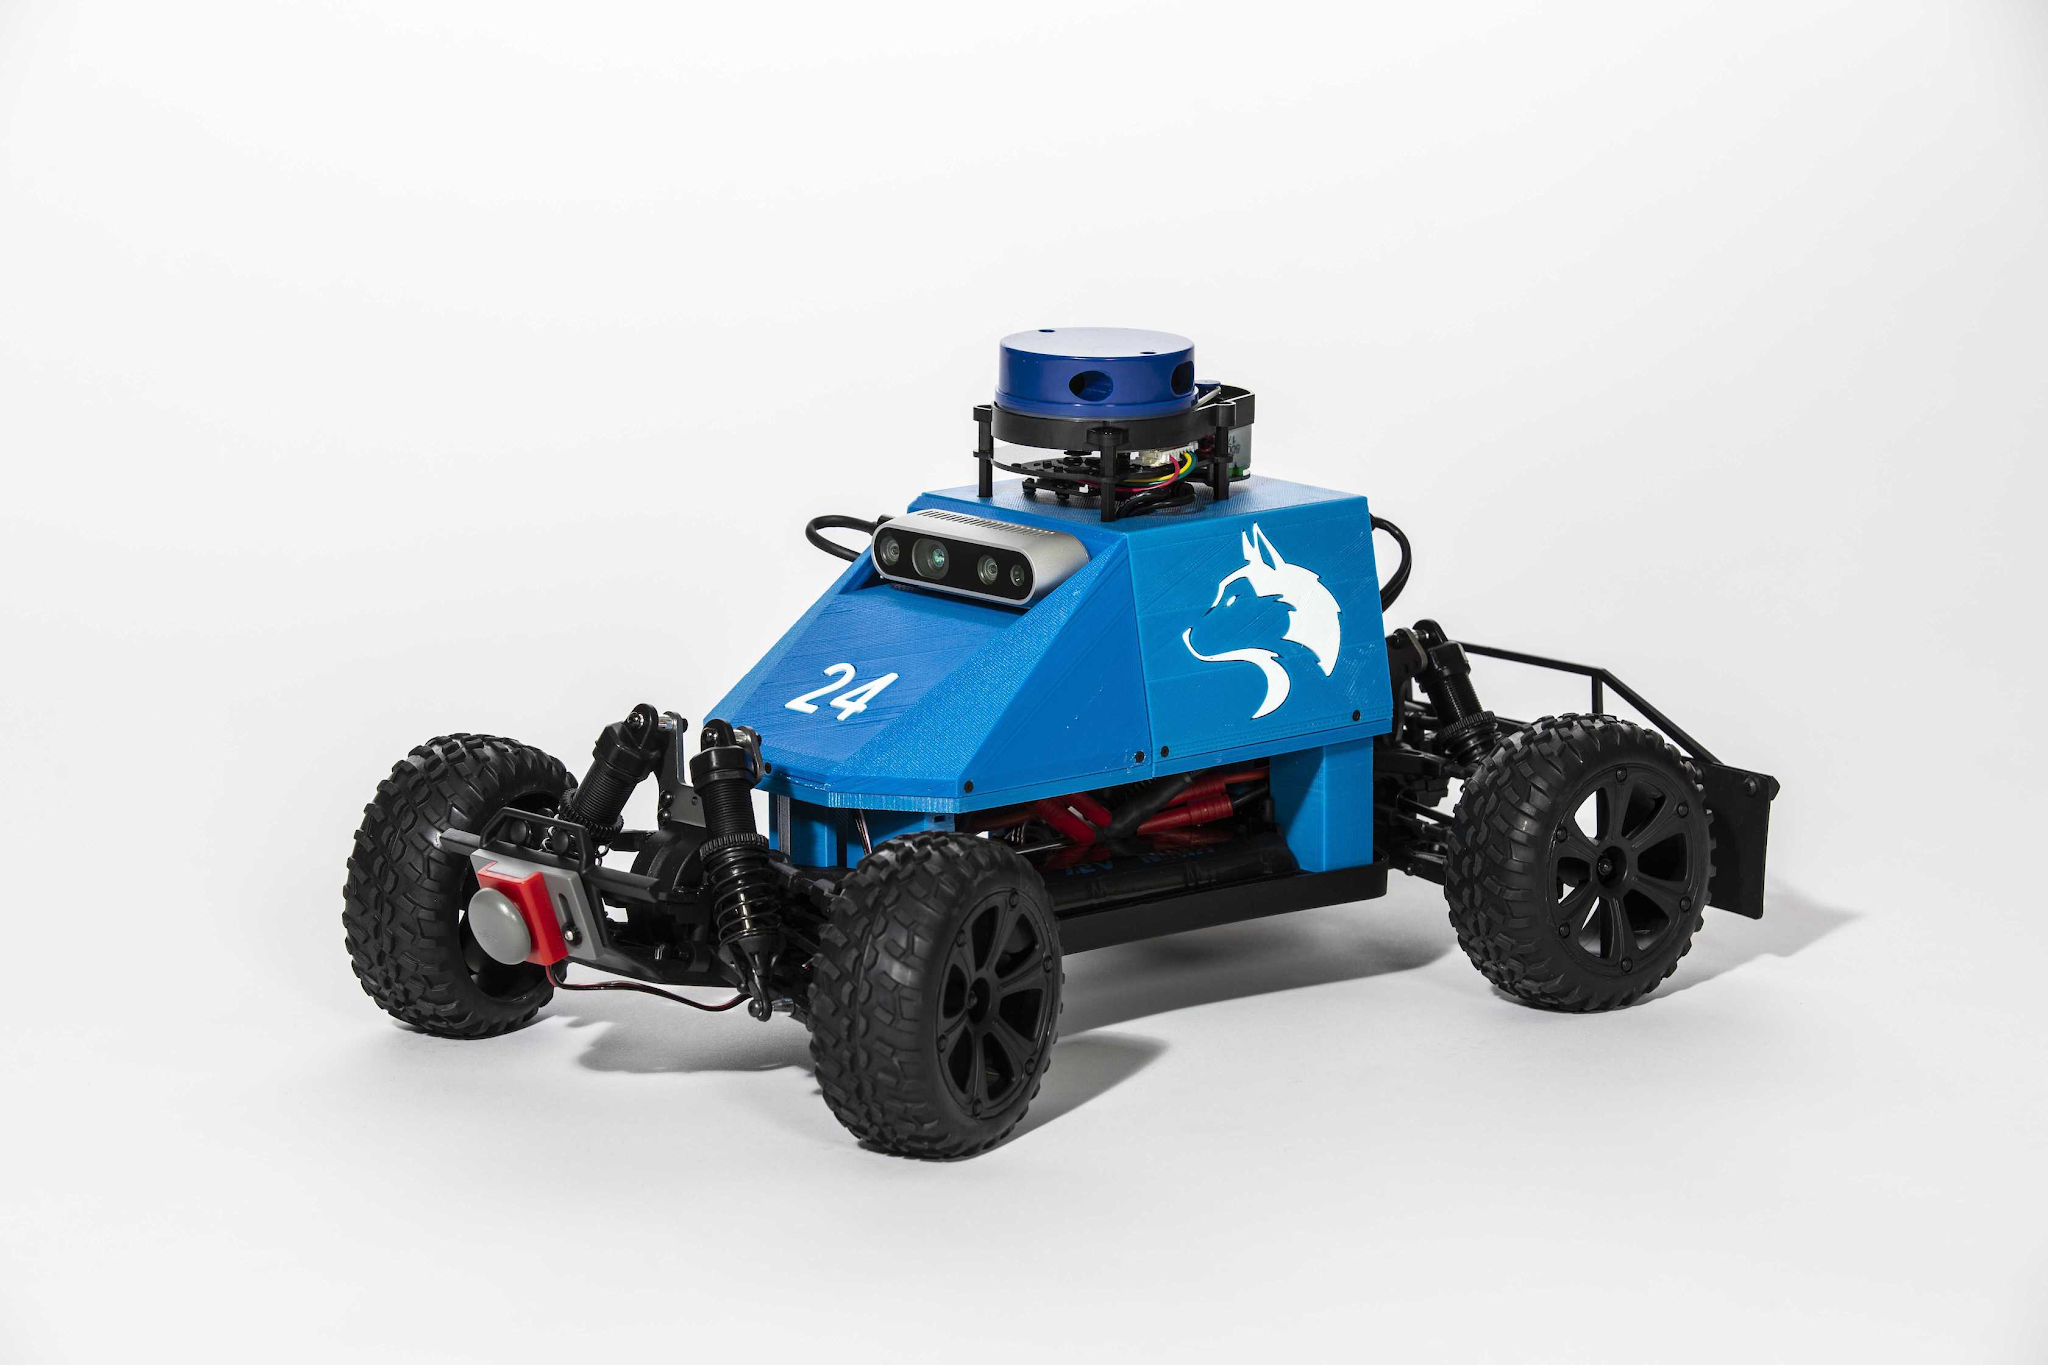
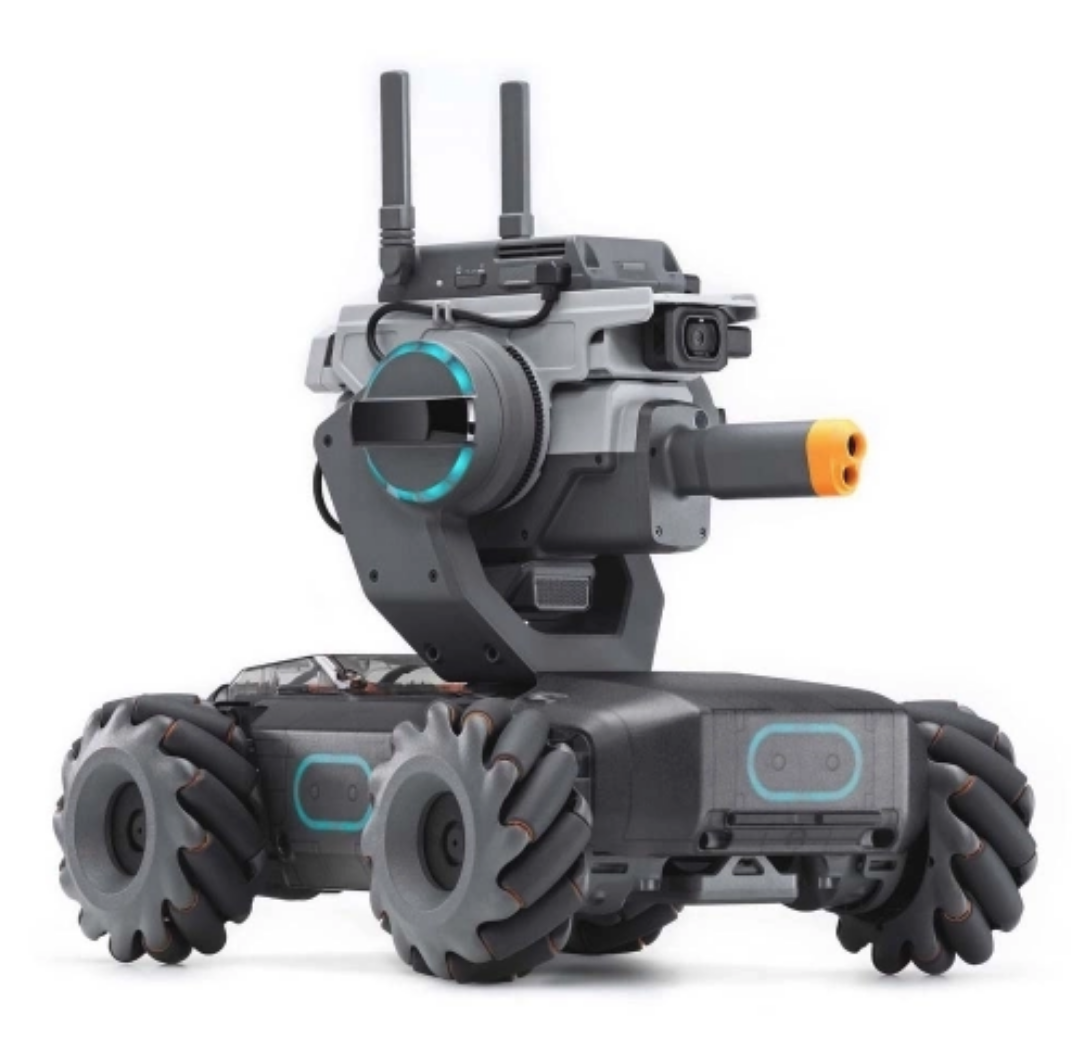
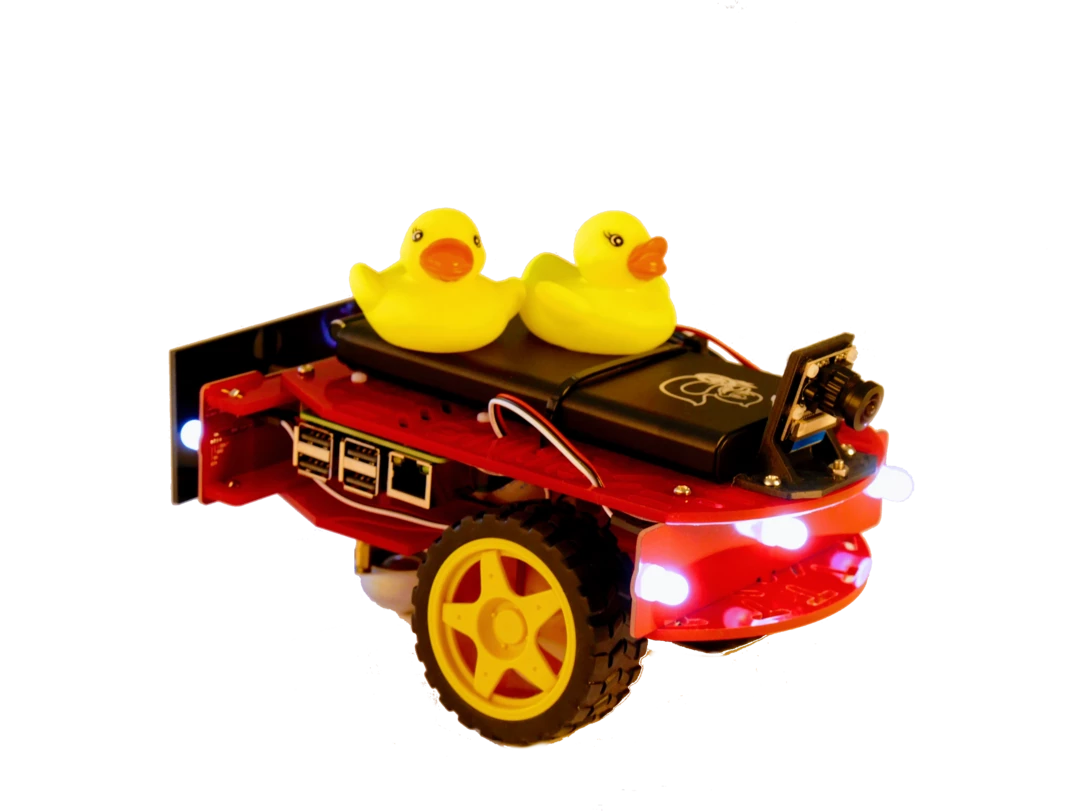
Existing wheeled robots
All too expensive to scale.
F1/10
F1/10 · $3,600
MuSHR
MuSHR · $900
DJI Robomaster
DJI Robomaster · $500
Duckiebot
Duckiebot · $280
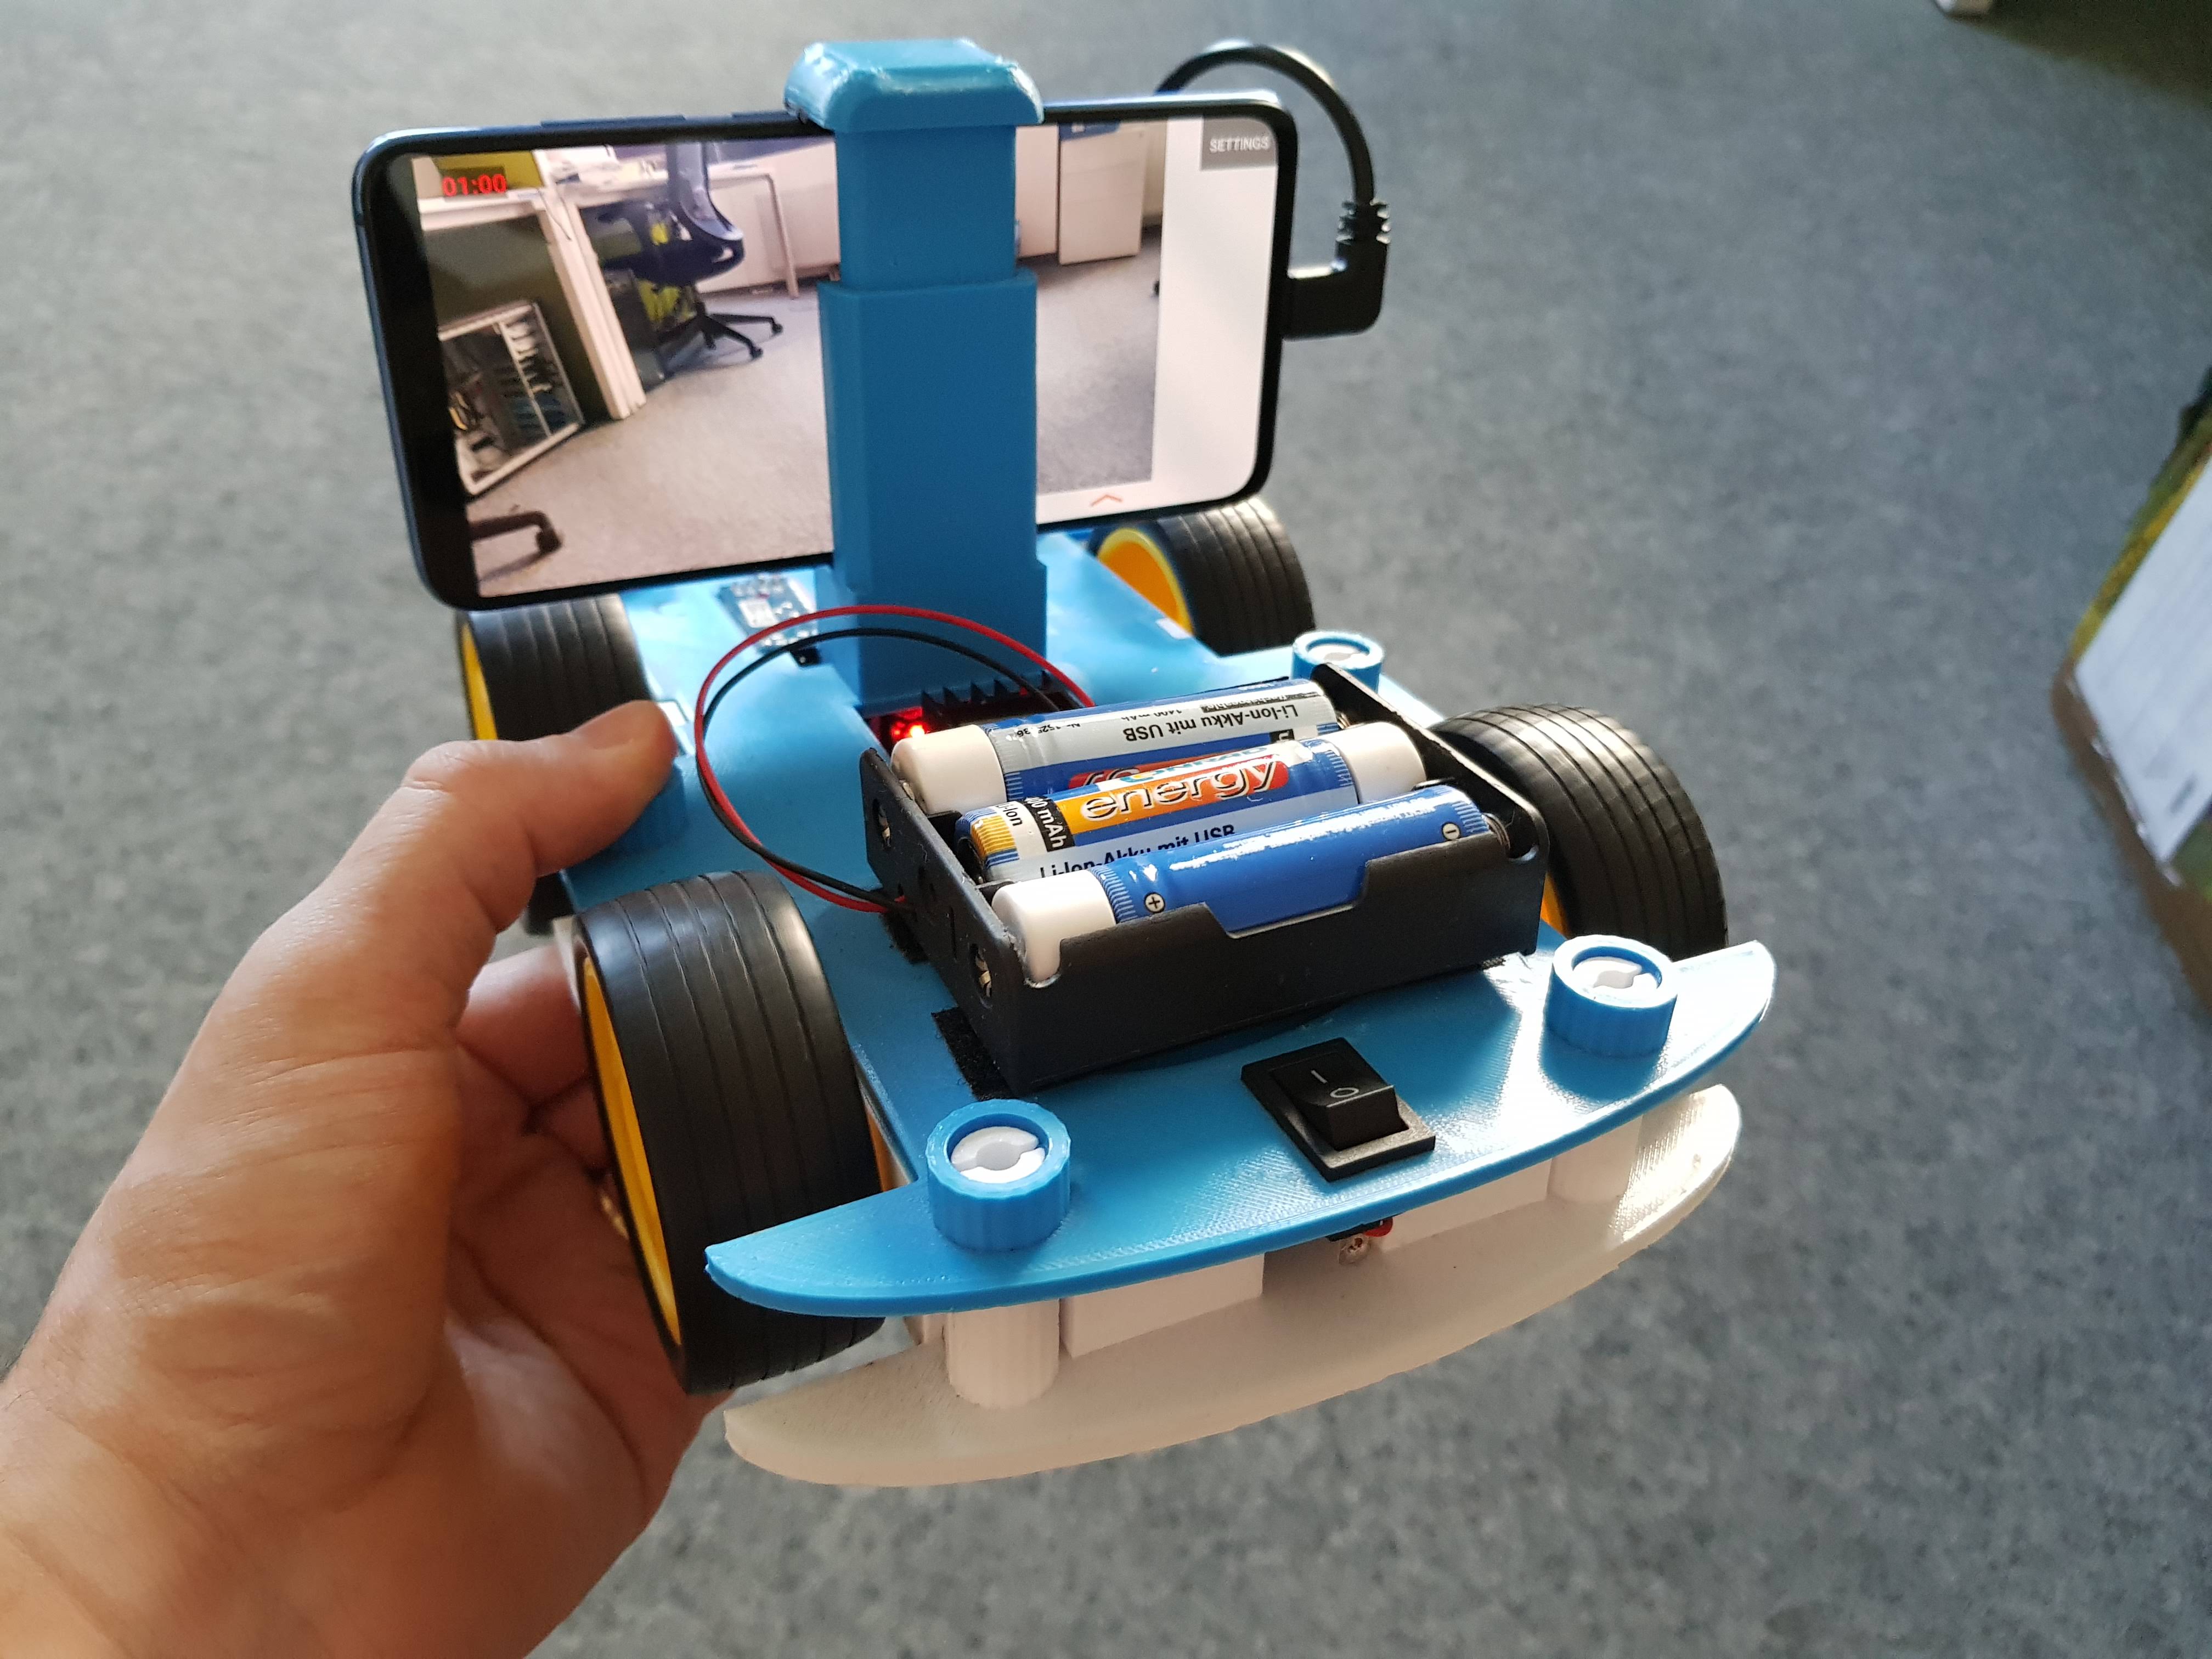
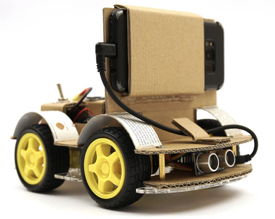
OpenBot
OpenBot
Smartphone brain + off-the-shelf parts
$50
Mechanical design
3D-printed body.

Prints in less than a day · $5 in PLA

OpenBot mechanical CAD
Electrical design
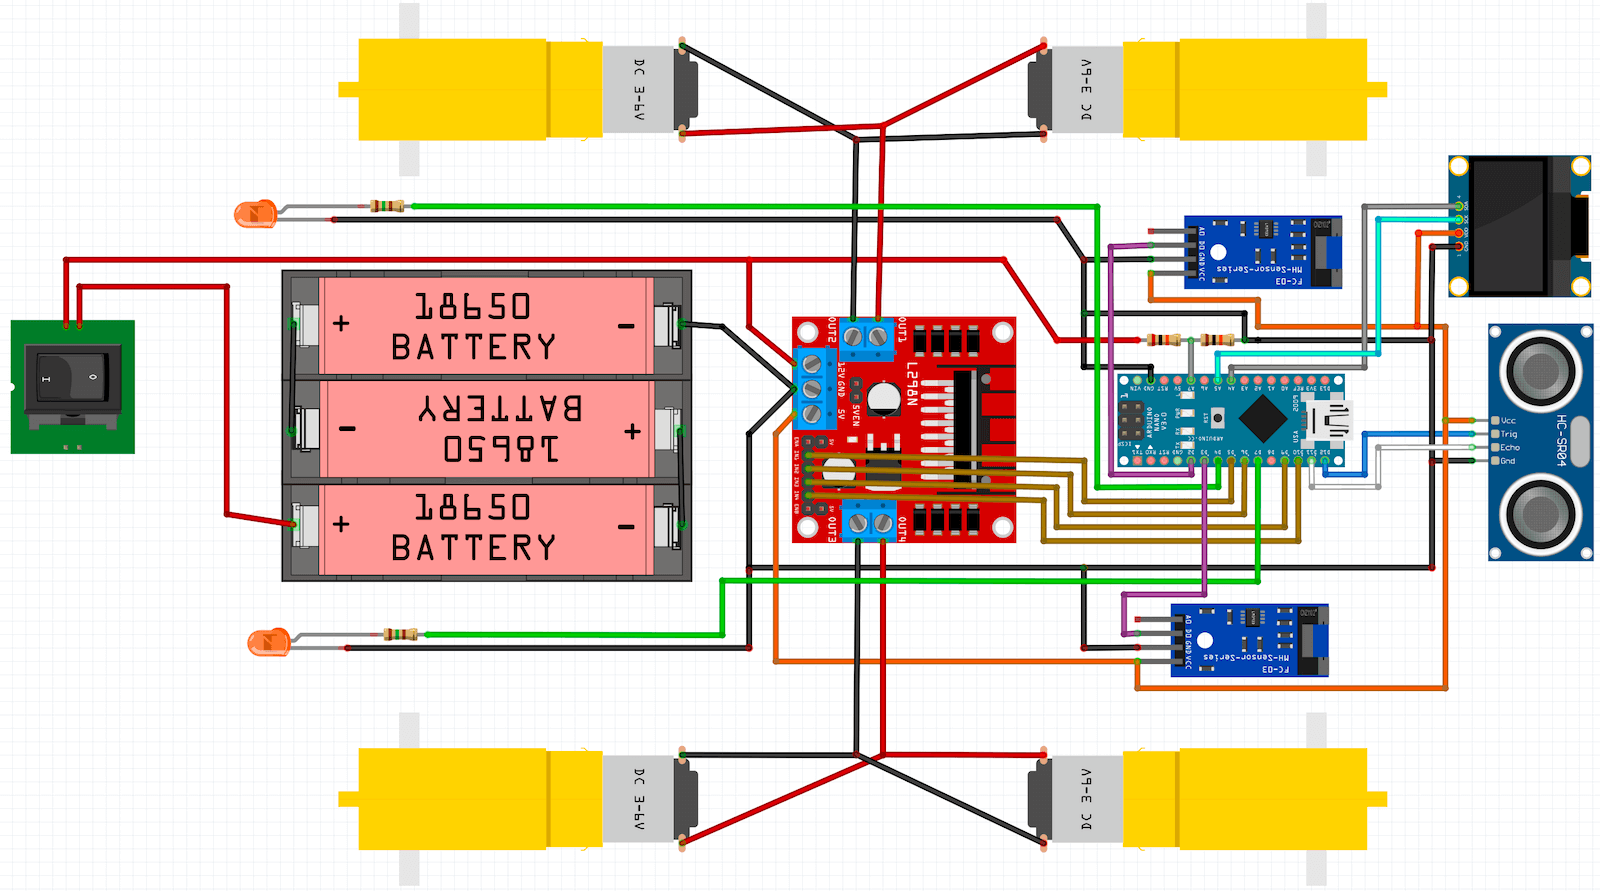
Arduino · motor driver · batteries · sensors.
Wiring
Wiring diagram
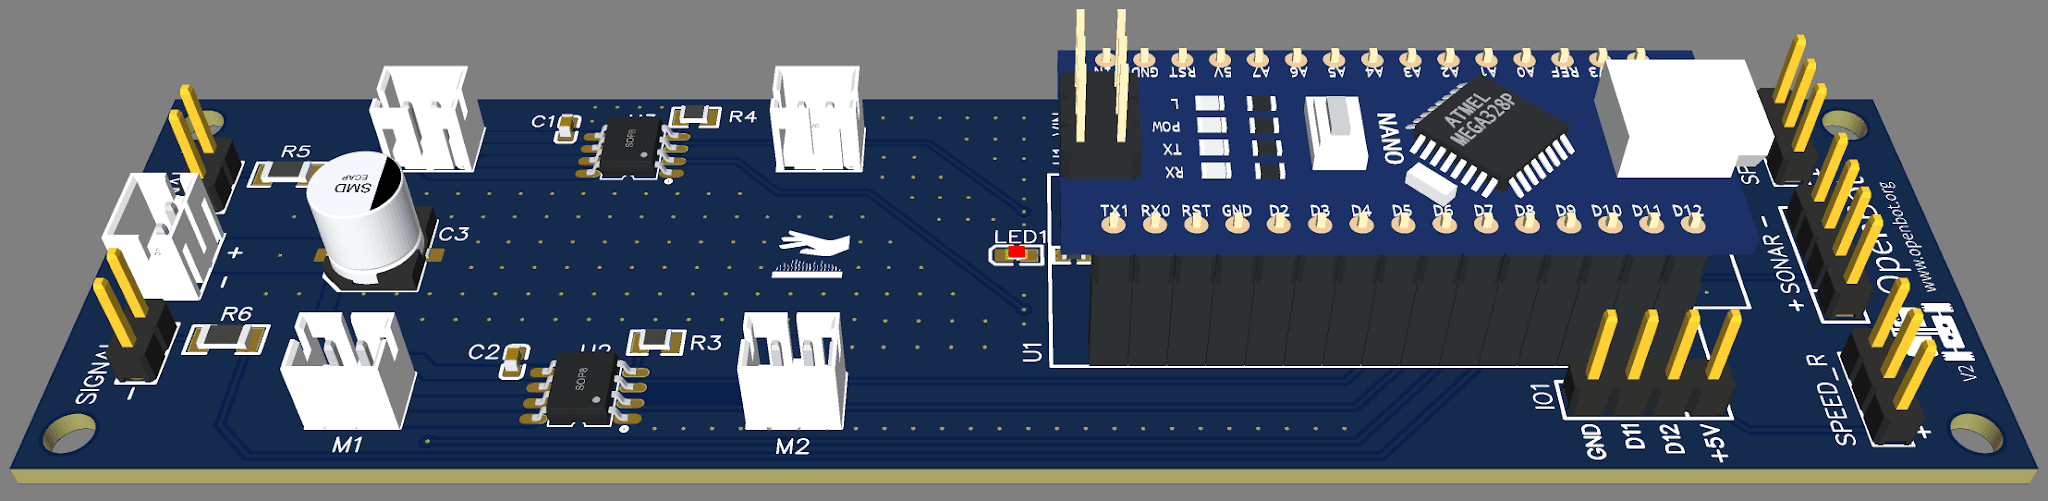
Optional PCB
OpenBot PCB

A PCB collapses the wire mess into one board you plug into — same circuit, no soldering jungle.

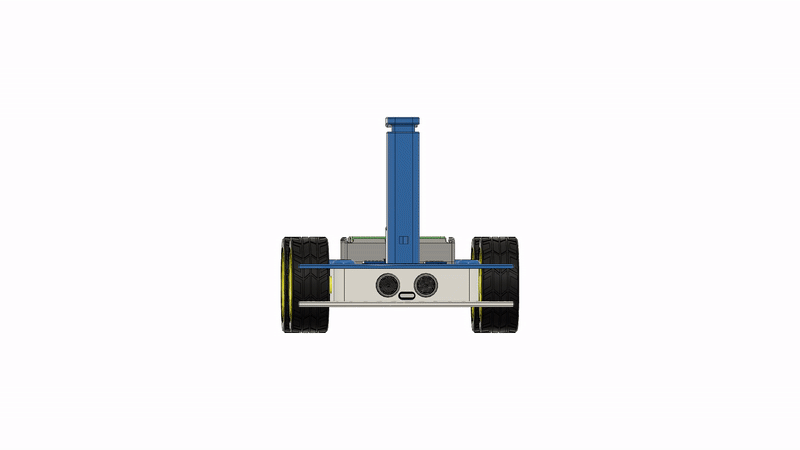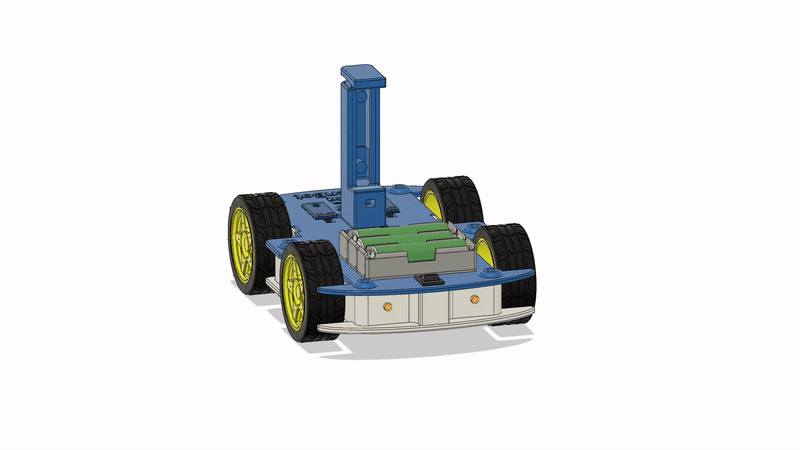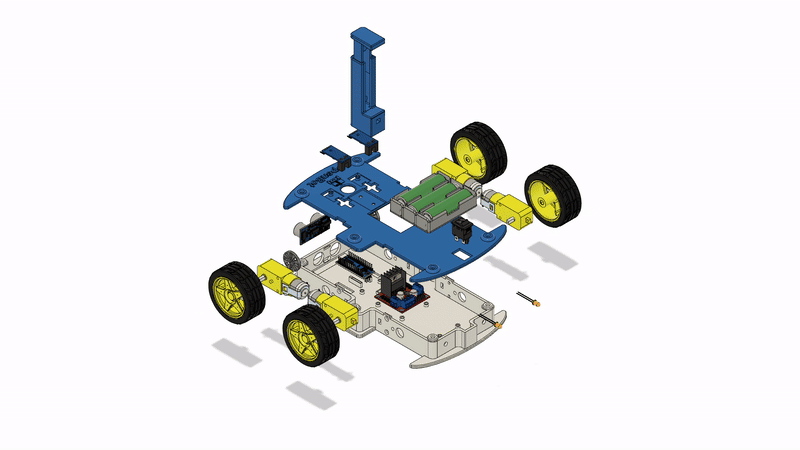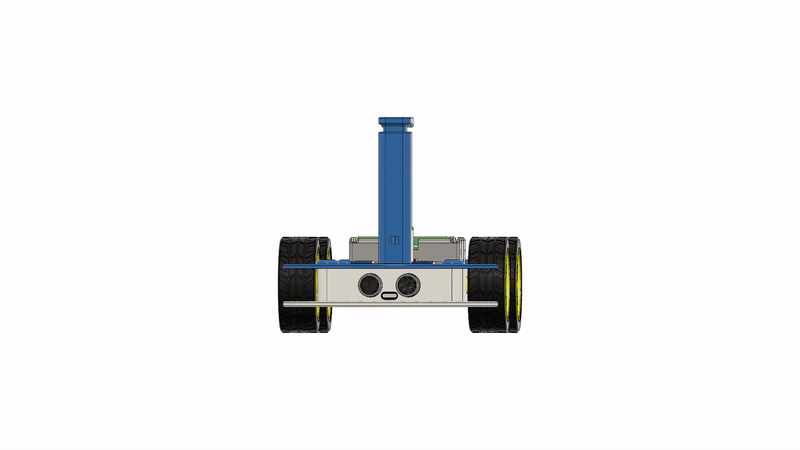
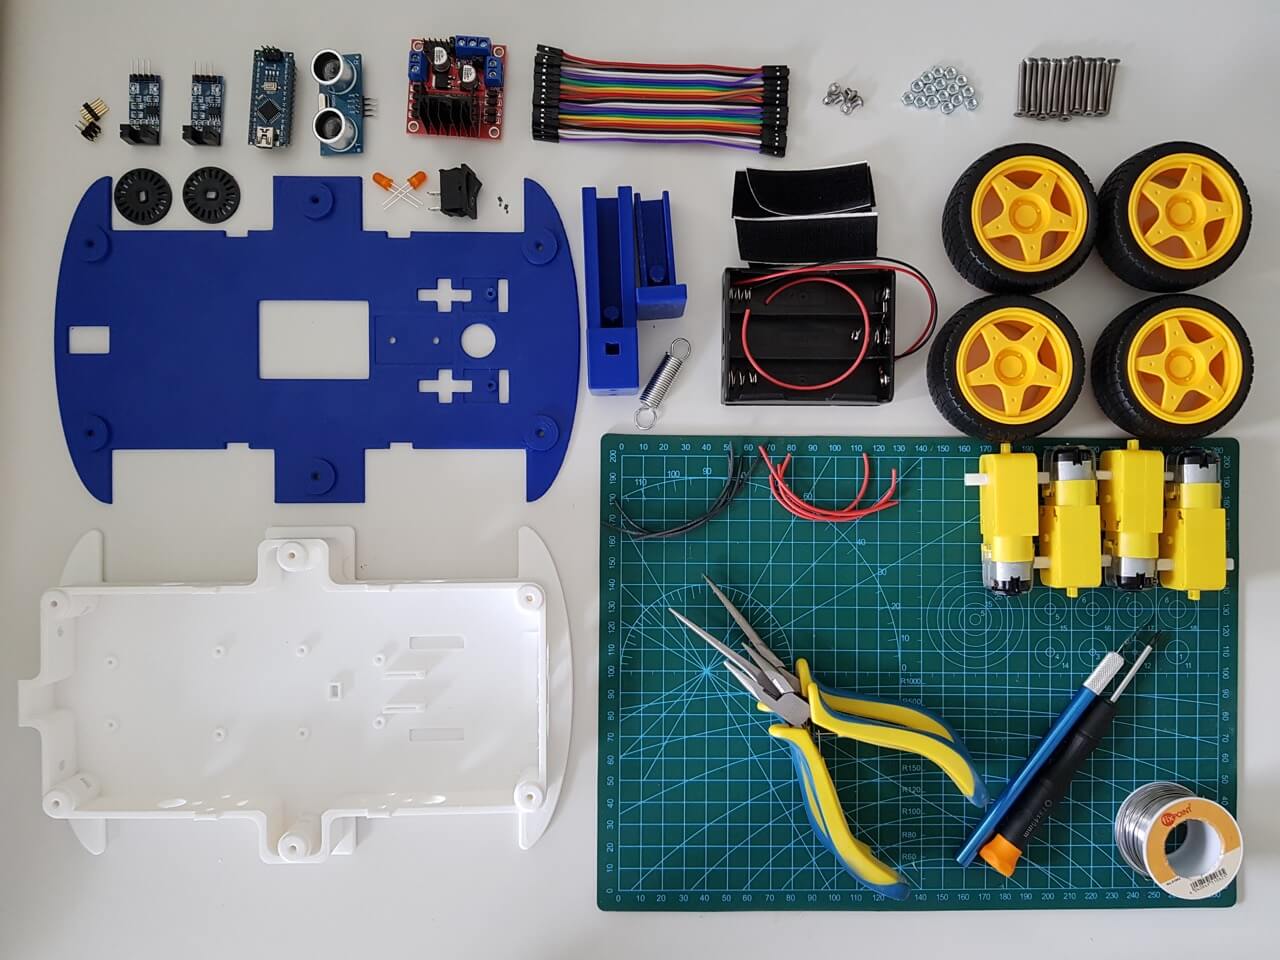
Hardware · Assembly
Build it in 15 minutes.

Off-the-shelf electronics · 3D-printed body · a screwdriver.

All the parts laid out
Bill of materials
Fifty bucks? A whole robot?
3D-printed body$5
Arduino Nano$8
4 motors + tires$14
Motor driver$3
3× 18650 batteries$15
Sonar + wheel encoders$5
Total
$50
($30 in bulk)

…and the brain you already have in your pocket.

The brain
Your phone is a robot computer.
📷
HD camera
🧠
CPU + GPU + AI chip
🧭
IMU + GPS
📶
WiFi · BT · 4G/5G
🔊 🎤 🖥
Speaker + mic + display
🔋
Battery + charging
Software stack
Smartphone runs the AI.
Microcontroller drives the motors.
📱 Smartphone · Android app
📷 Camera + IMU + GPS
🧠 Neural net (TF Lite)
📊 Sensor logger
🔊 Voice + display
⇄
USB
— or —
BLUETOOTH
⚙️ Robot body · MCU
🔧 PWM motor control
🛞 Wheel encoders
📡 Sonar
🔋 Battery monitor
Beyond the phone
Three ways to drive and train it.
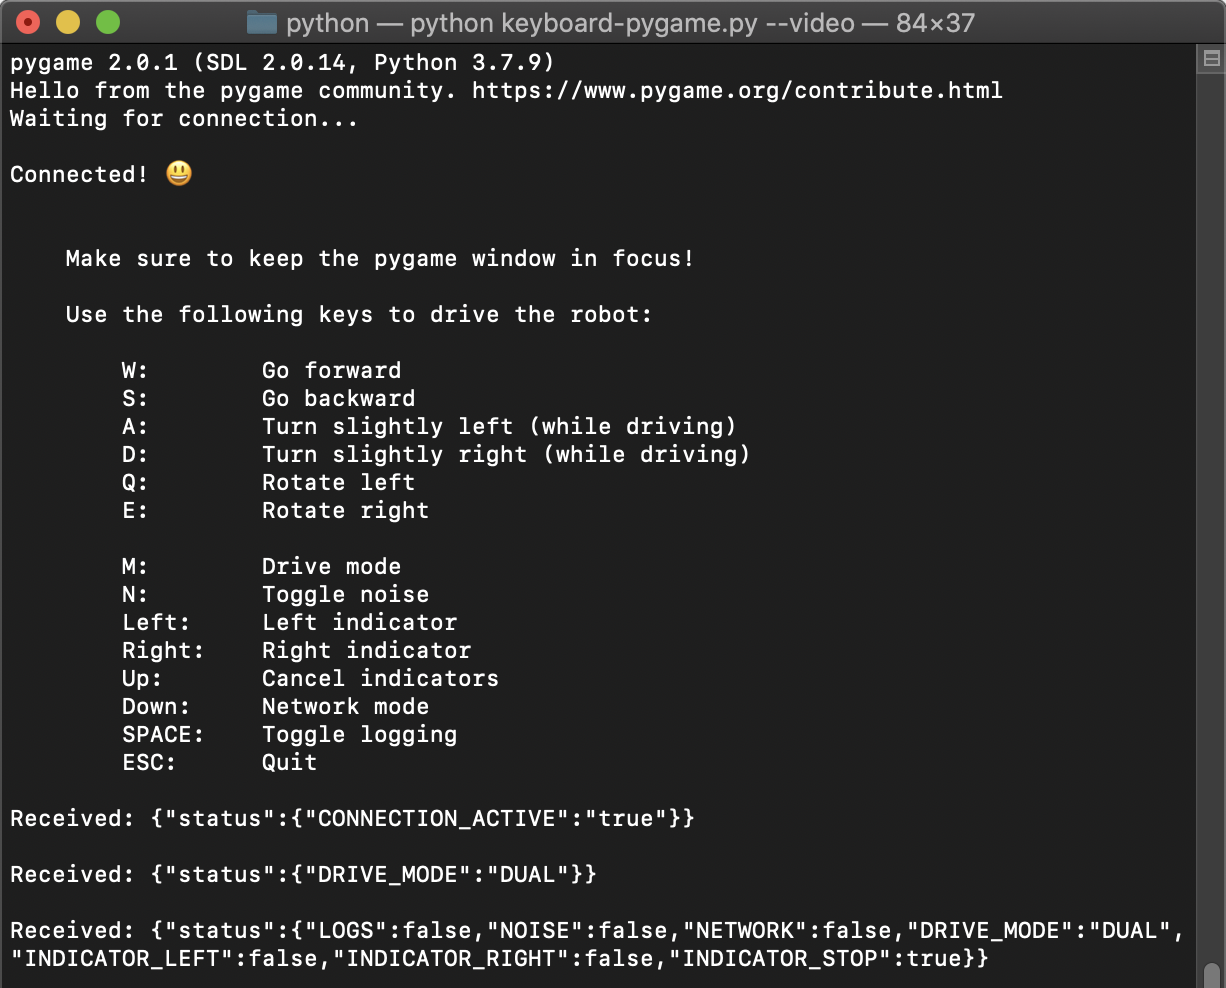
Python SDK
🐍 Python SDK
Control the robot from Python
Policy training web app
🌐 Policy training app
Train driving policies in-browser
Live teleop web app
📡 Live teleop
Web app · live video · Node.js backend
AI App #1
Person following.
📷
Camera frame
→
SSD + MobileNet
tiny detector designed for phones
trained on COCO · 90 classes
→
🎯
Bounding box
around the person
Pick the target
Only consider person detections above 50% confidence. If there are multiple people, follow the one with the highest score.
Visual servoing
Steer so the center of the bounding box stays in the middle of the frame. Speed up when the box gets small, slow down when it gets big.

Runs in real time on any modern smartphone — quantized model, CPU-only, no cloud.

AI App #2
Autonomous navigation.

Similar to Tesla Autopilot — an end-to-end neural network that drives the car autonomously.

CIL architecture refresher
Conditional Imitation Learning — recap from earlier

We took that — and shrank it to fit on a phone.

Autonomous nav · the model
Same accuracy as the big nets.
7× smaller.
PilotNet · 9.6M params
92% · 83%
distance · success
CIL · 10.7M params
94% · 89%
distance · success
Ours · 1.3M params
94% · 89%
distance · success

⚡ Runs faster than real-time on pretty much any modern phone.

Coffee Racer
Autonomous coffee delivery.
OpenBot-Fleet · ICRA 2024
From 1 robot to 72 homes.

If we want robots to work in your house, we can't train in one lab.

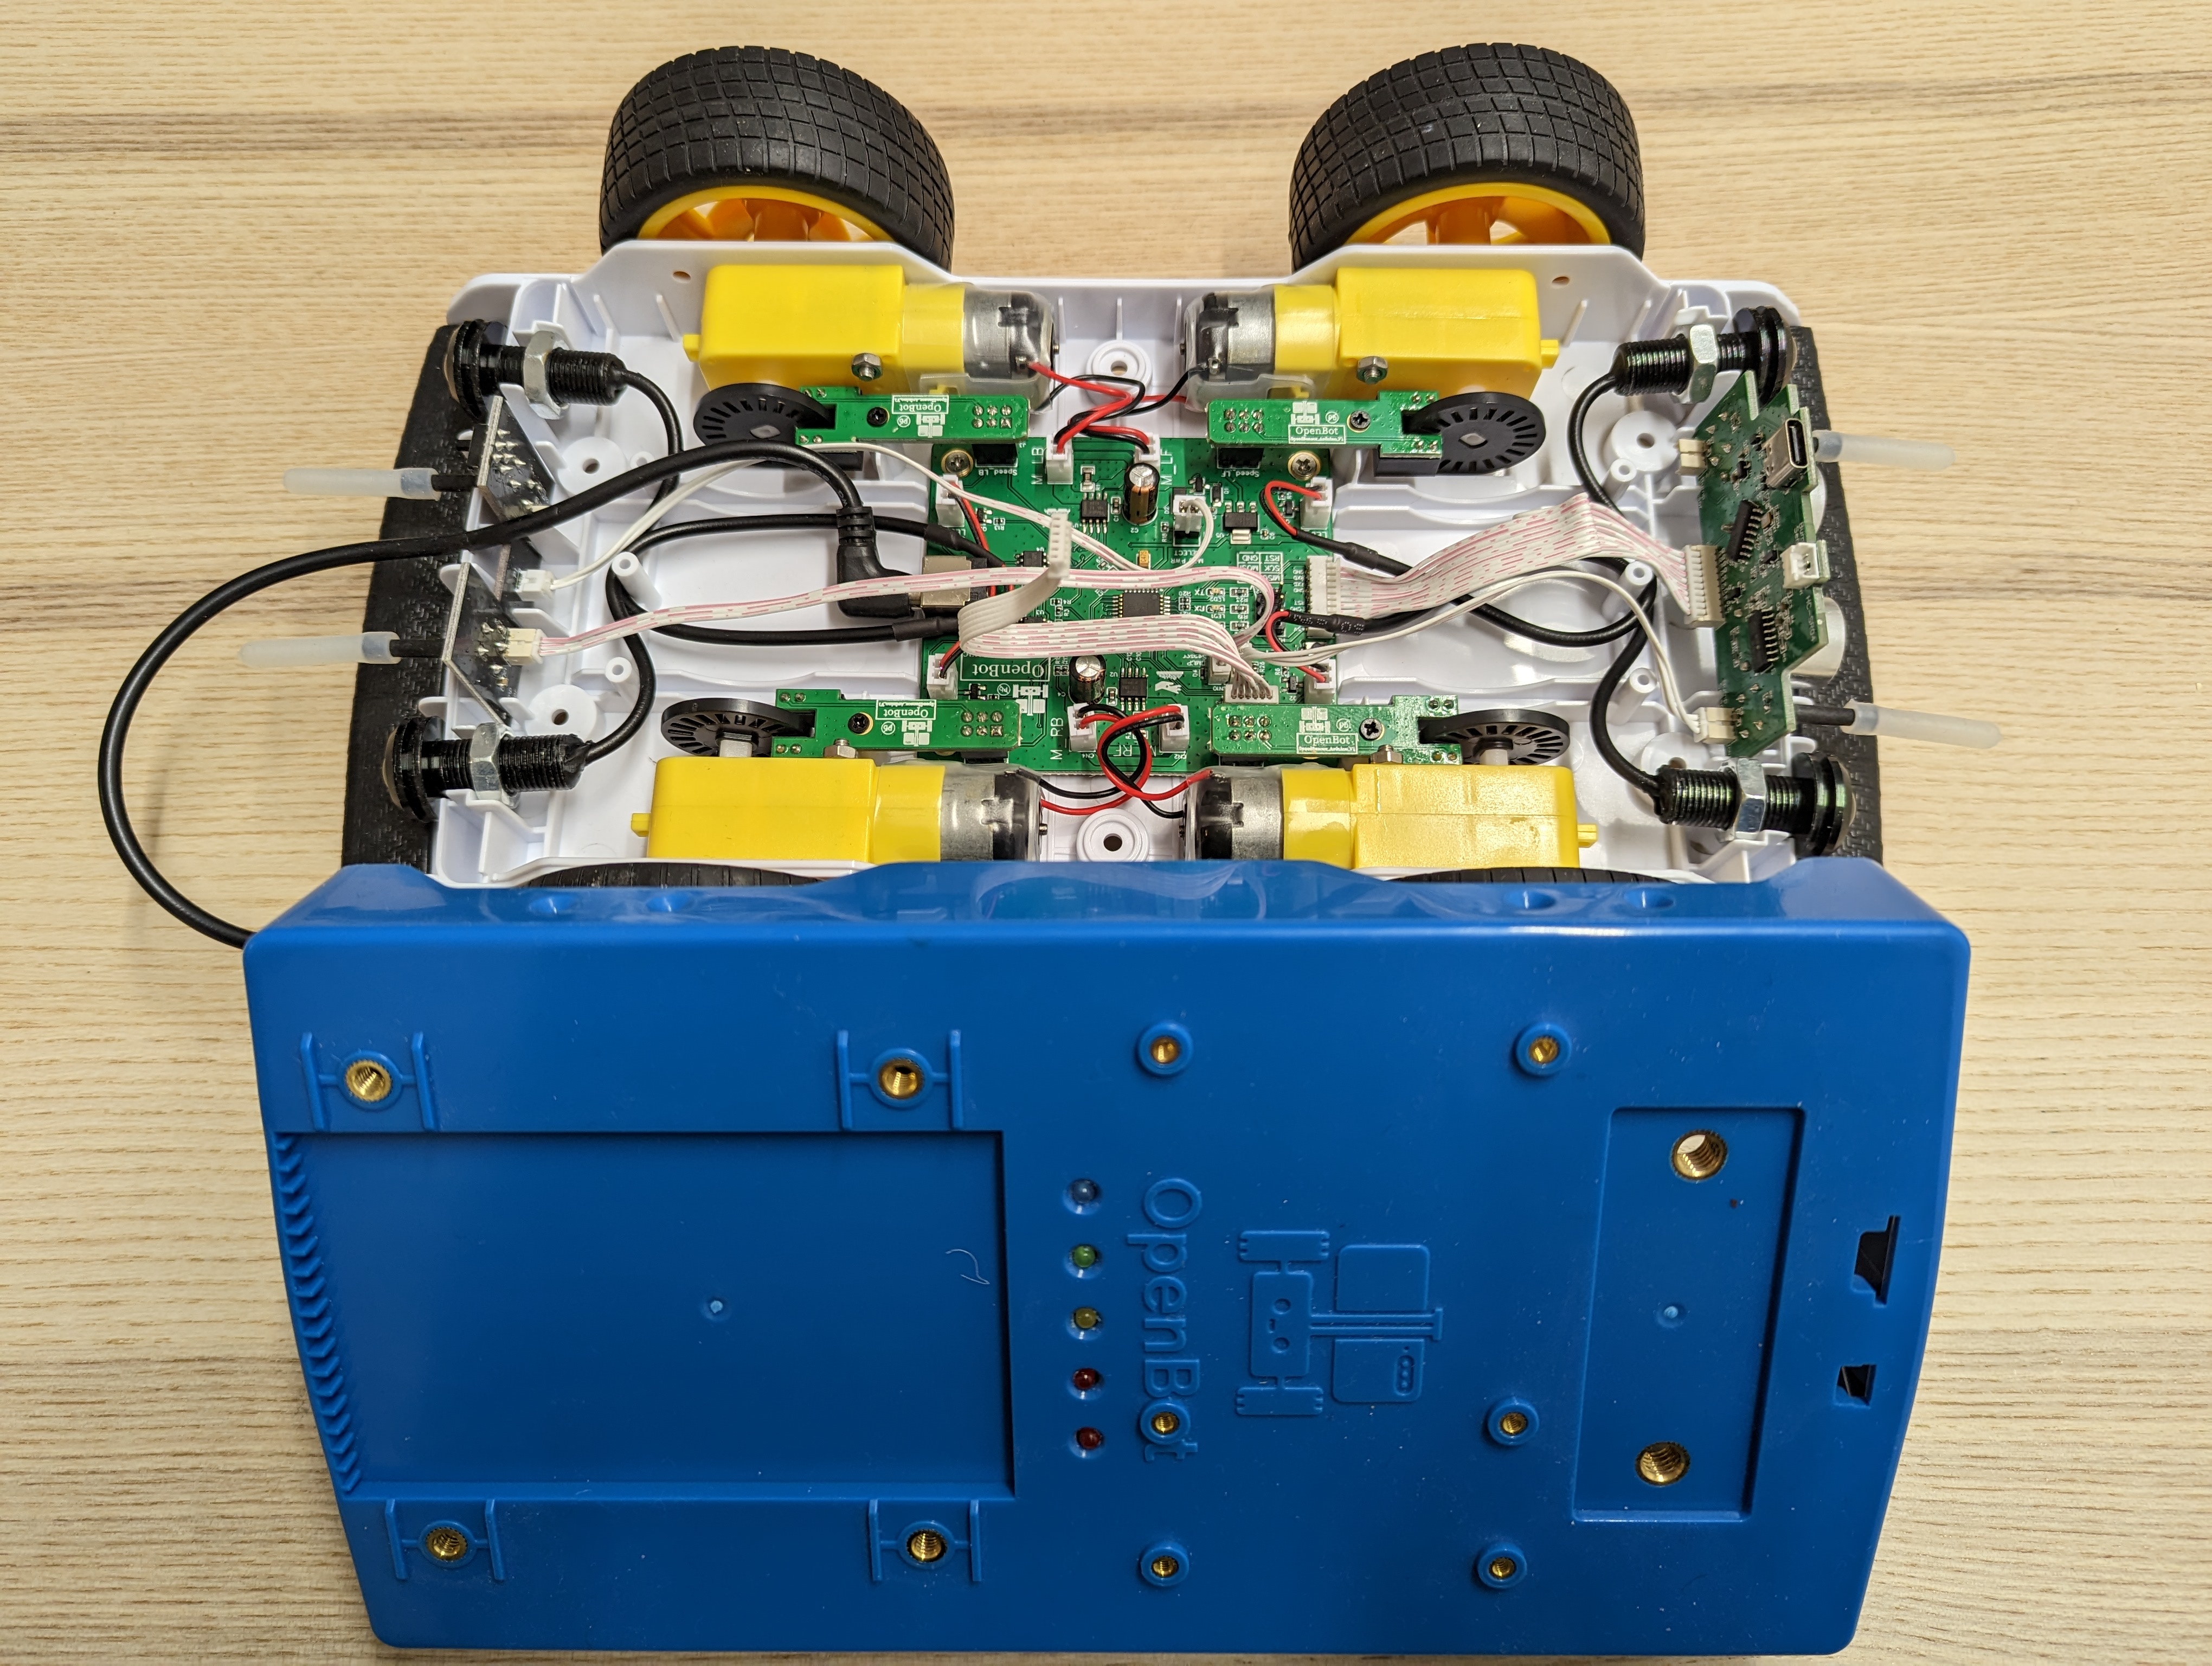
Hardware V2
Injection-molded · plug-and-play.

DIY was great for makers. 72 robots need real production · same cost, more durable.

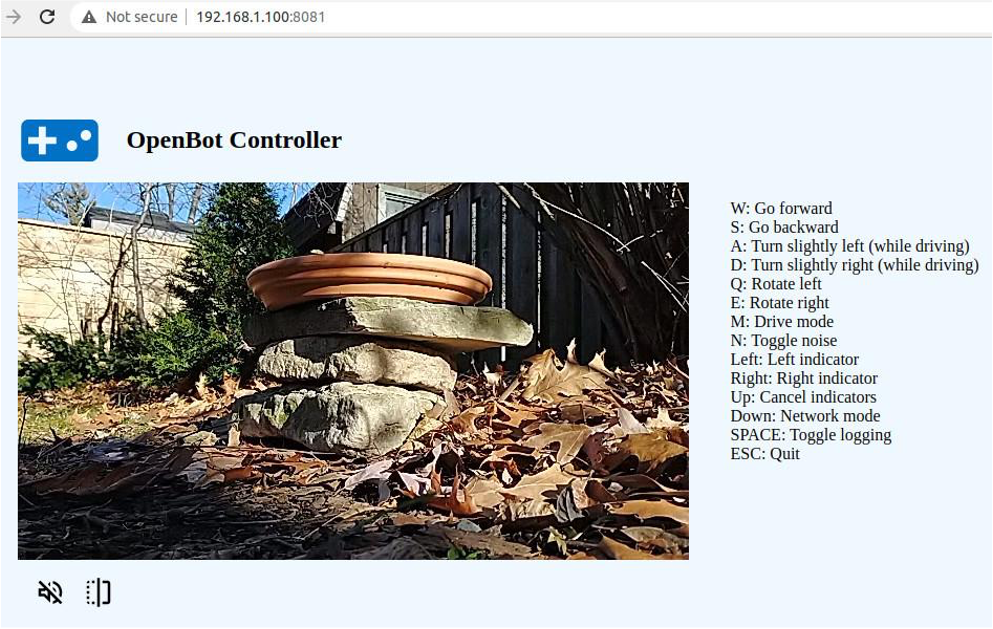
OpenBot V2 product
OpenBot fleet
The cloud loop
Robots collect data.
Policy updates in the cloud.
Fleet gets the new policy.
72 robots
in real homes
⇄
☁️
Firebase
storage · sync
⇄
🧠
RL training
TF-Agents · SAC

15,642 recordings · 1M+ frames · self-supervised U-Net floor segmentation.

Fleet results
Diversity beats data quantity.
Zero-shot · unseen homes
Best baseline15%
Ours60%
+ <200 finetune episodes82.5%
Diversity ablation · success rate
1 env50%
6 envs70%
72 envs85%

Same data per env. 1 home → 50%. 72 homes → 85%. Where the data comes from matters more than how much.

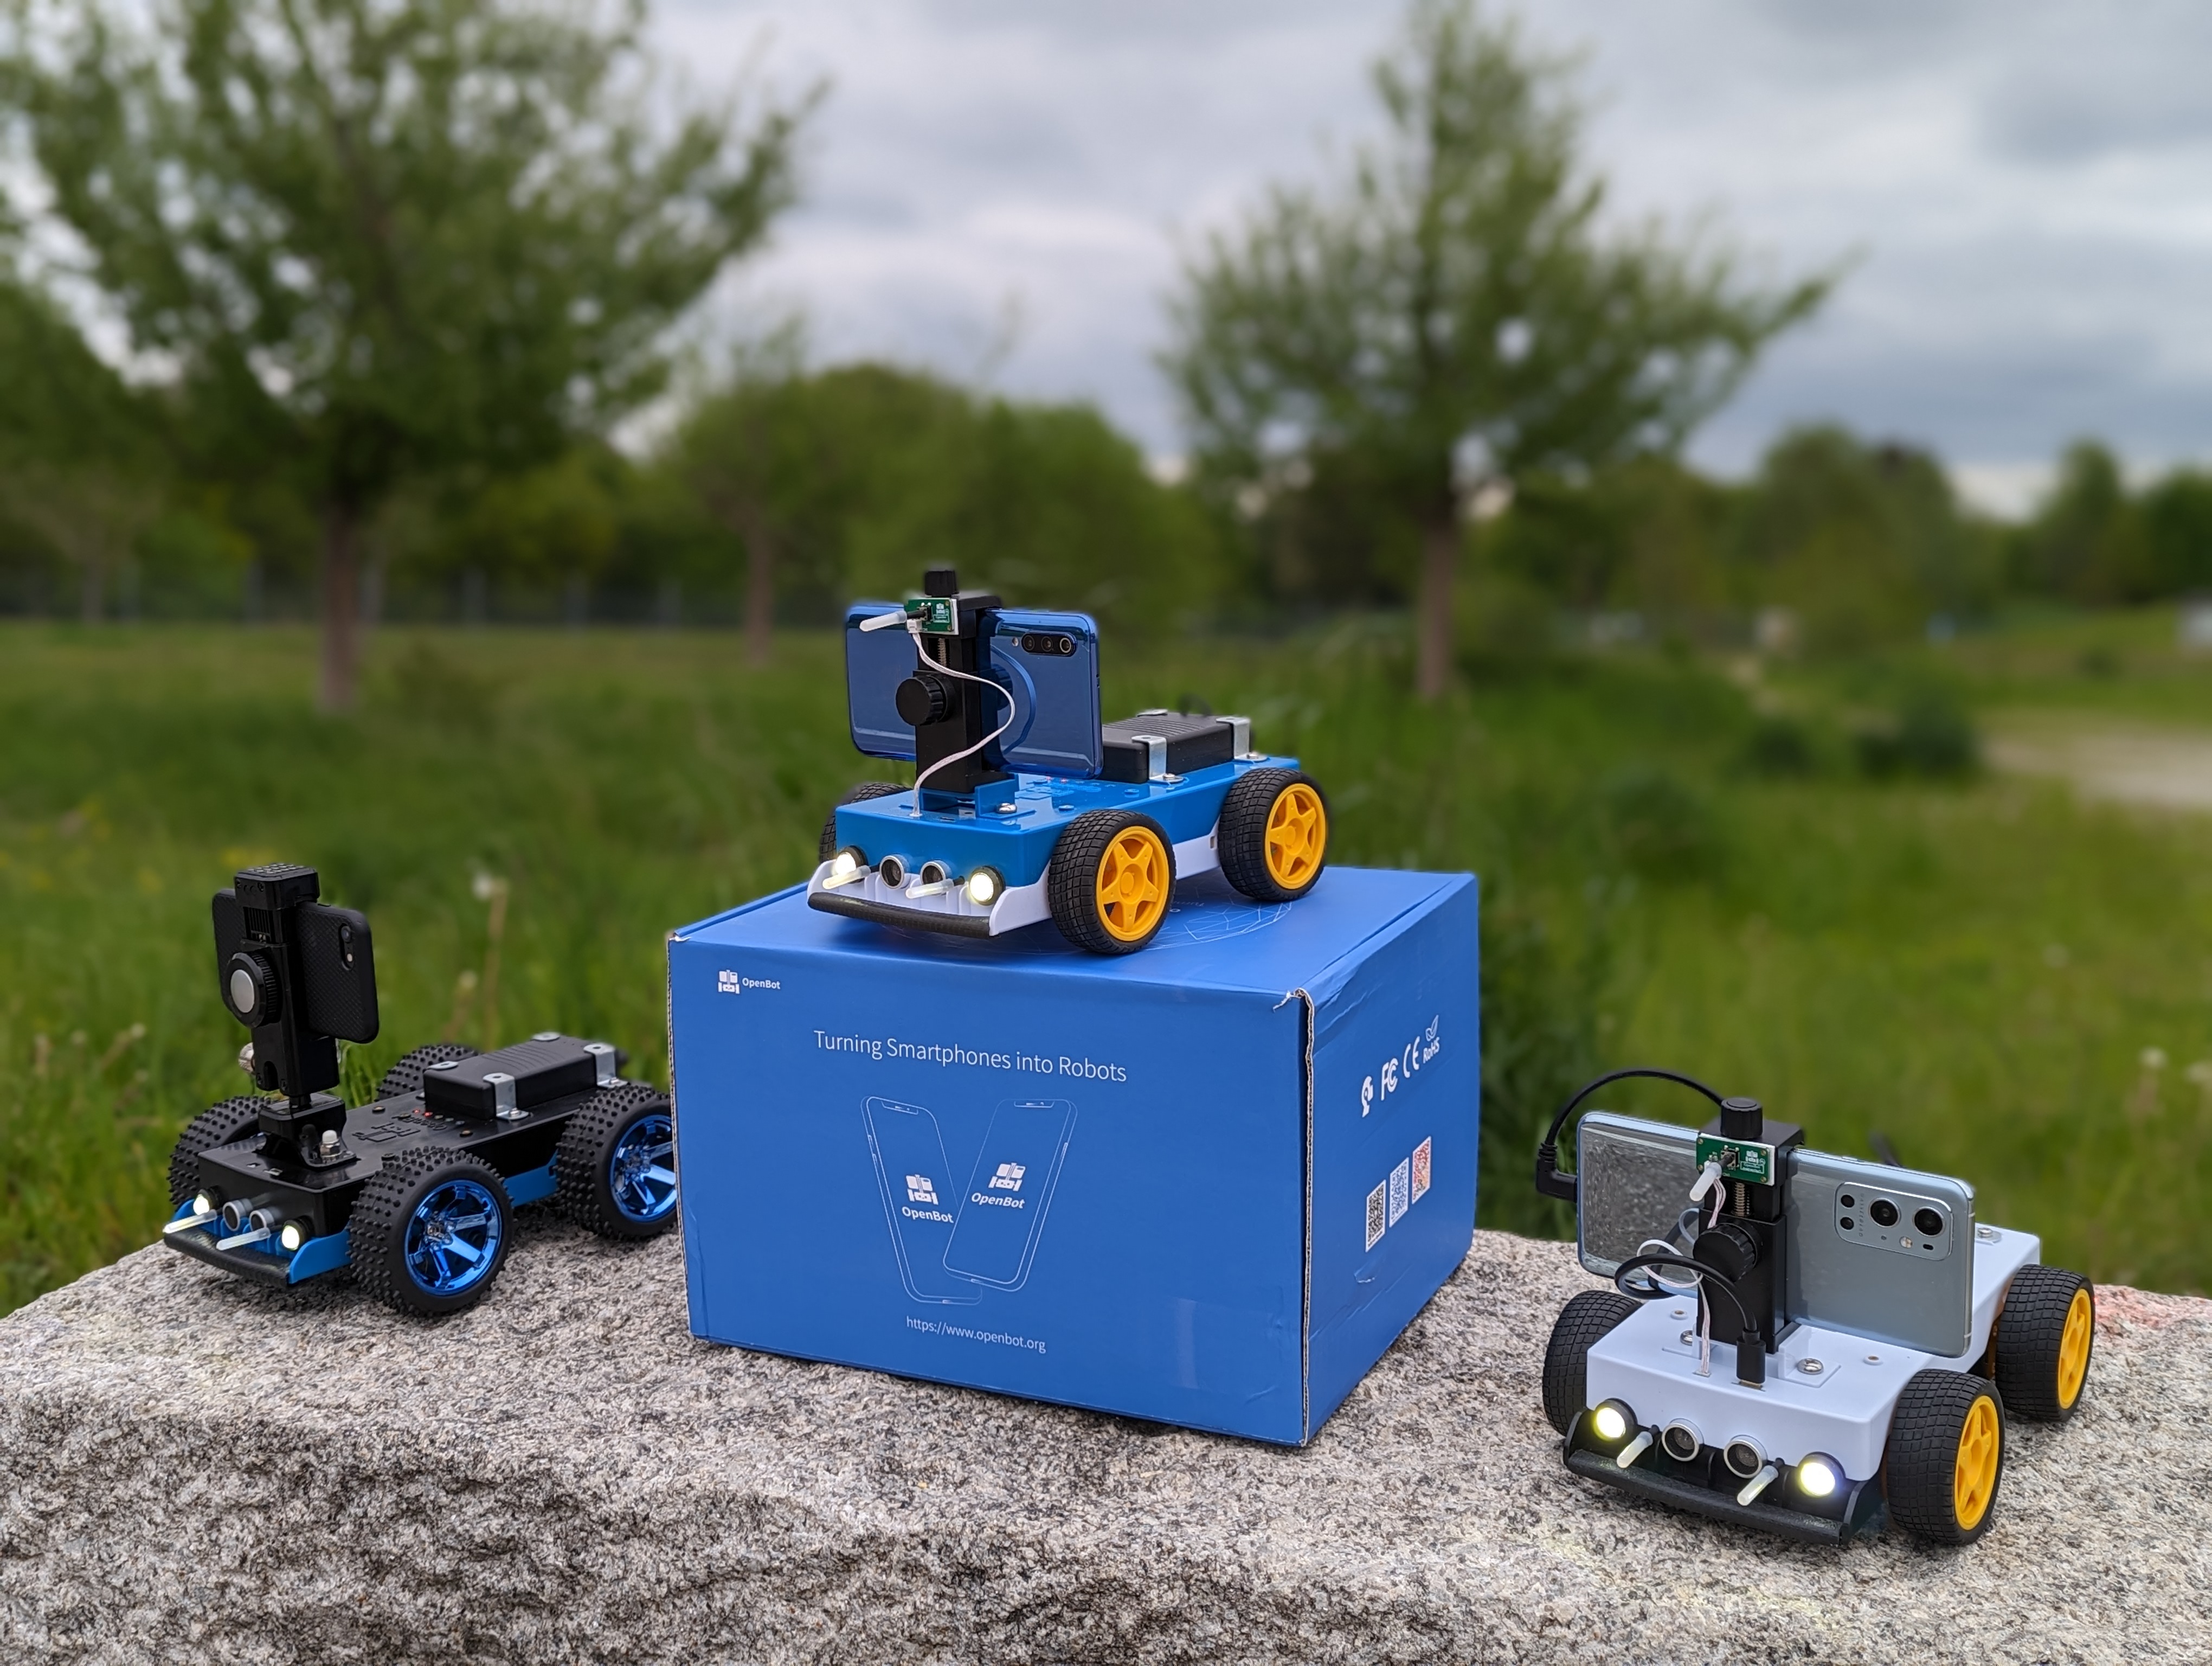
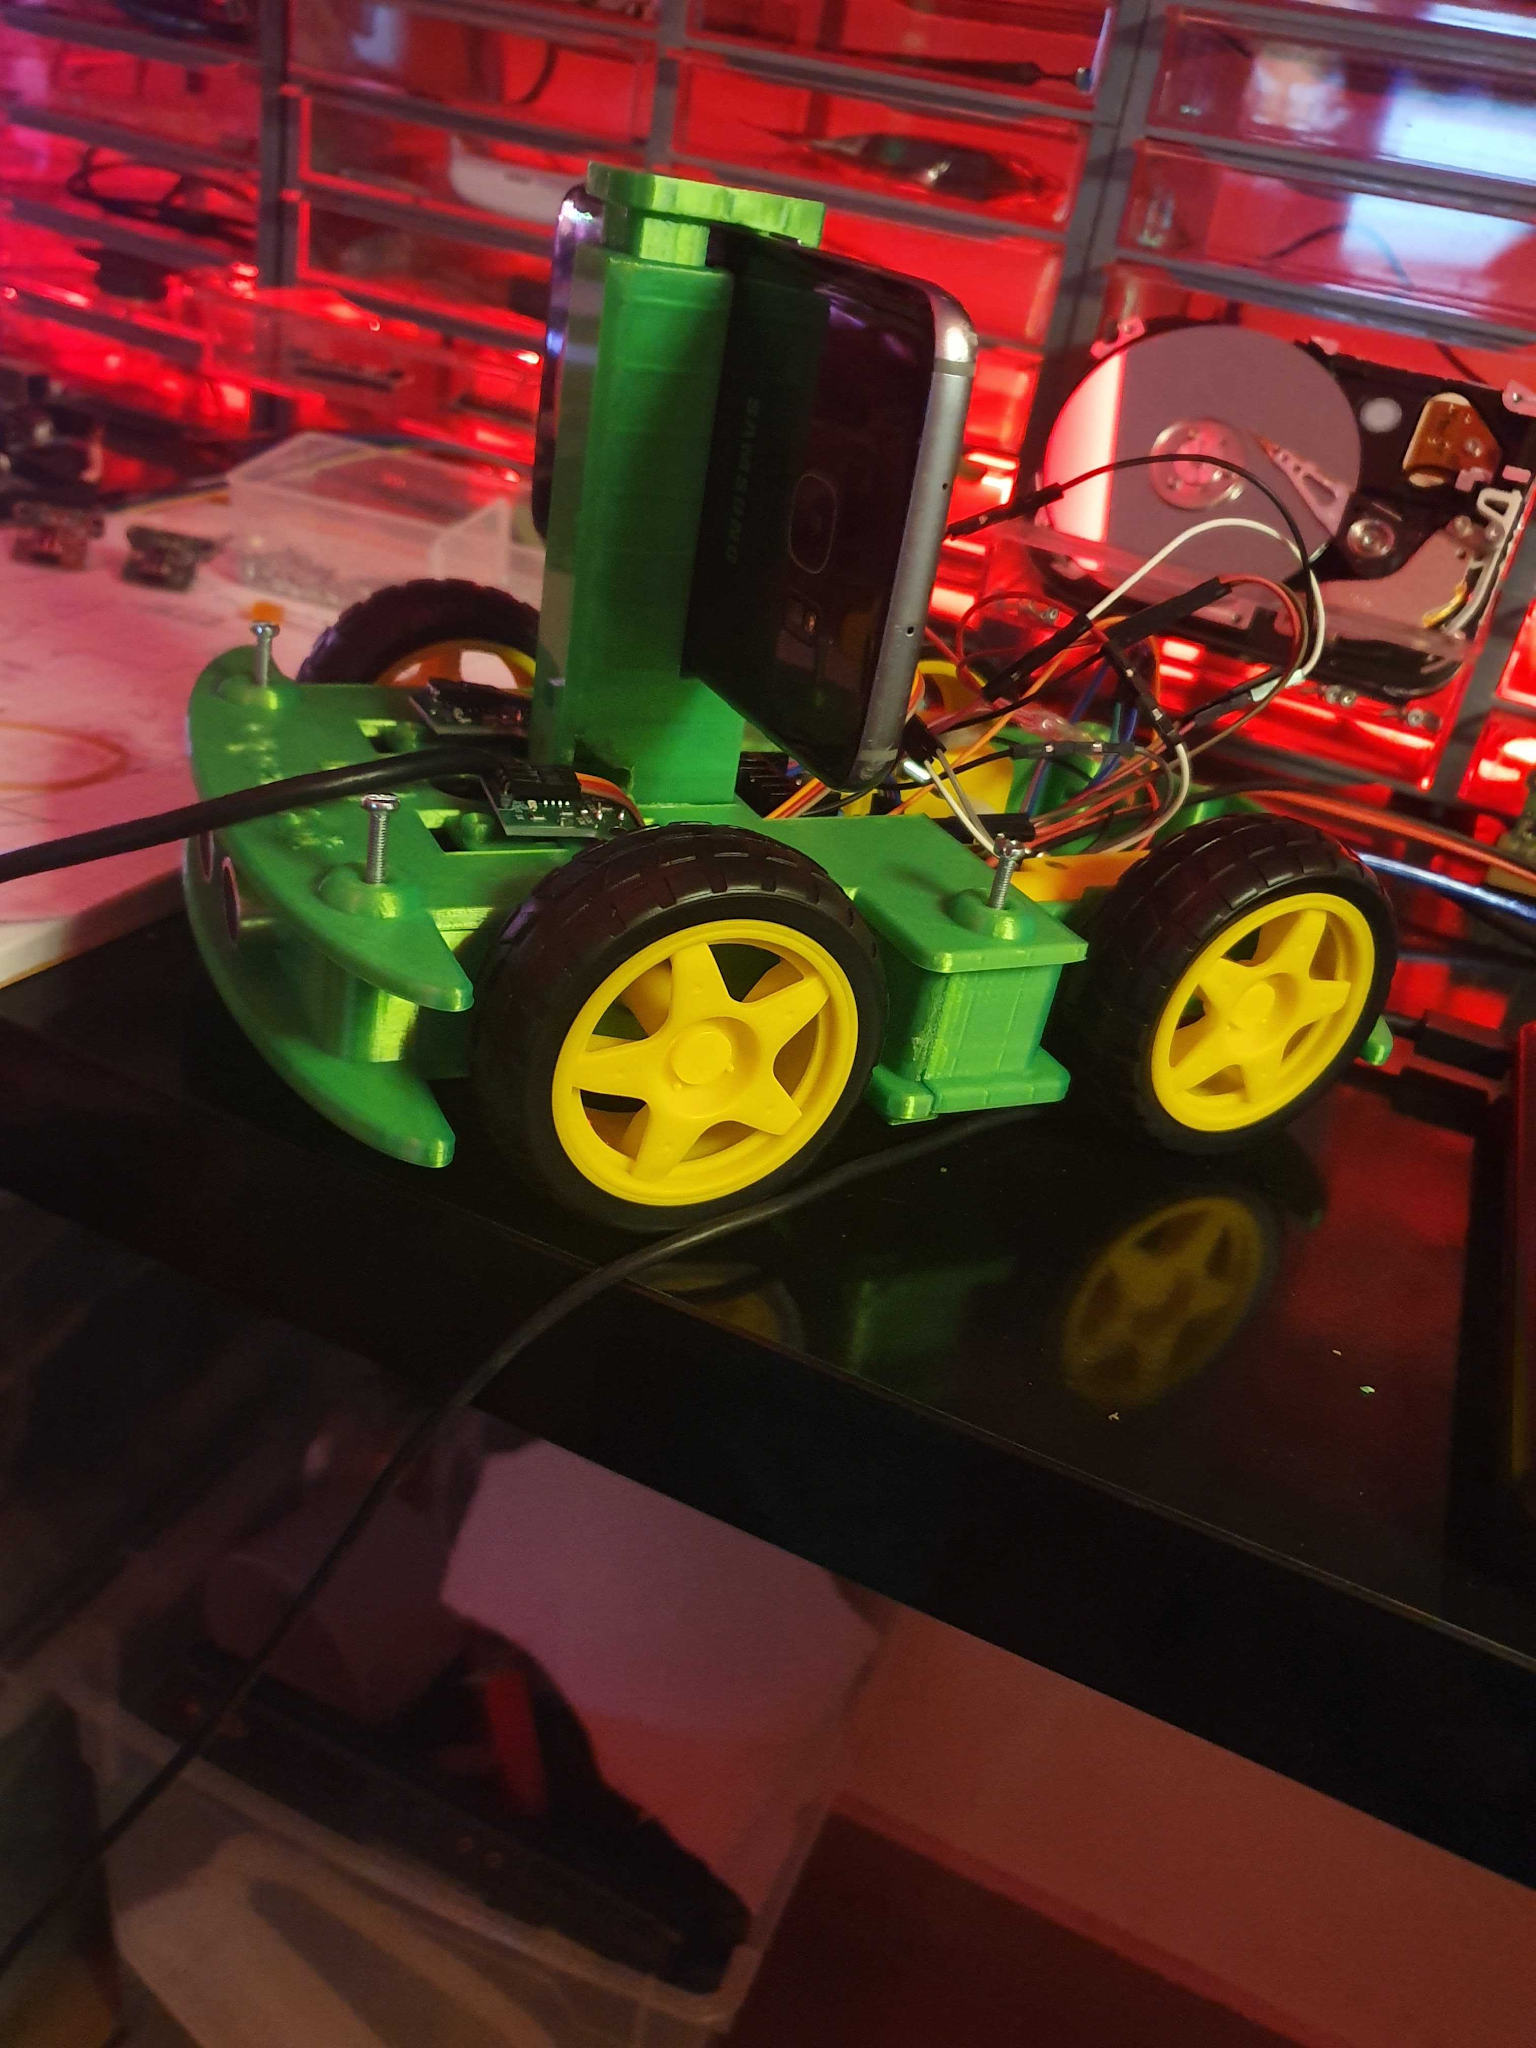
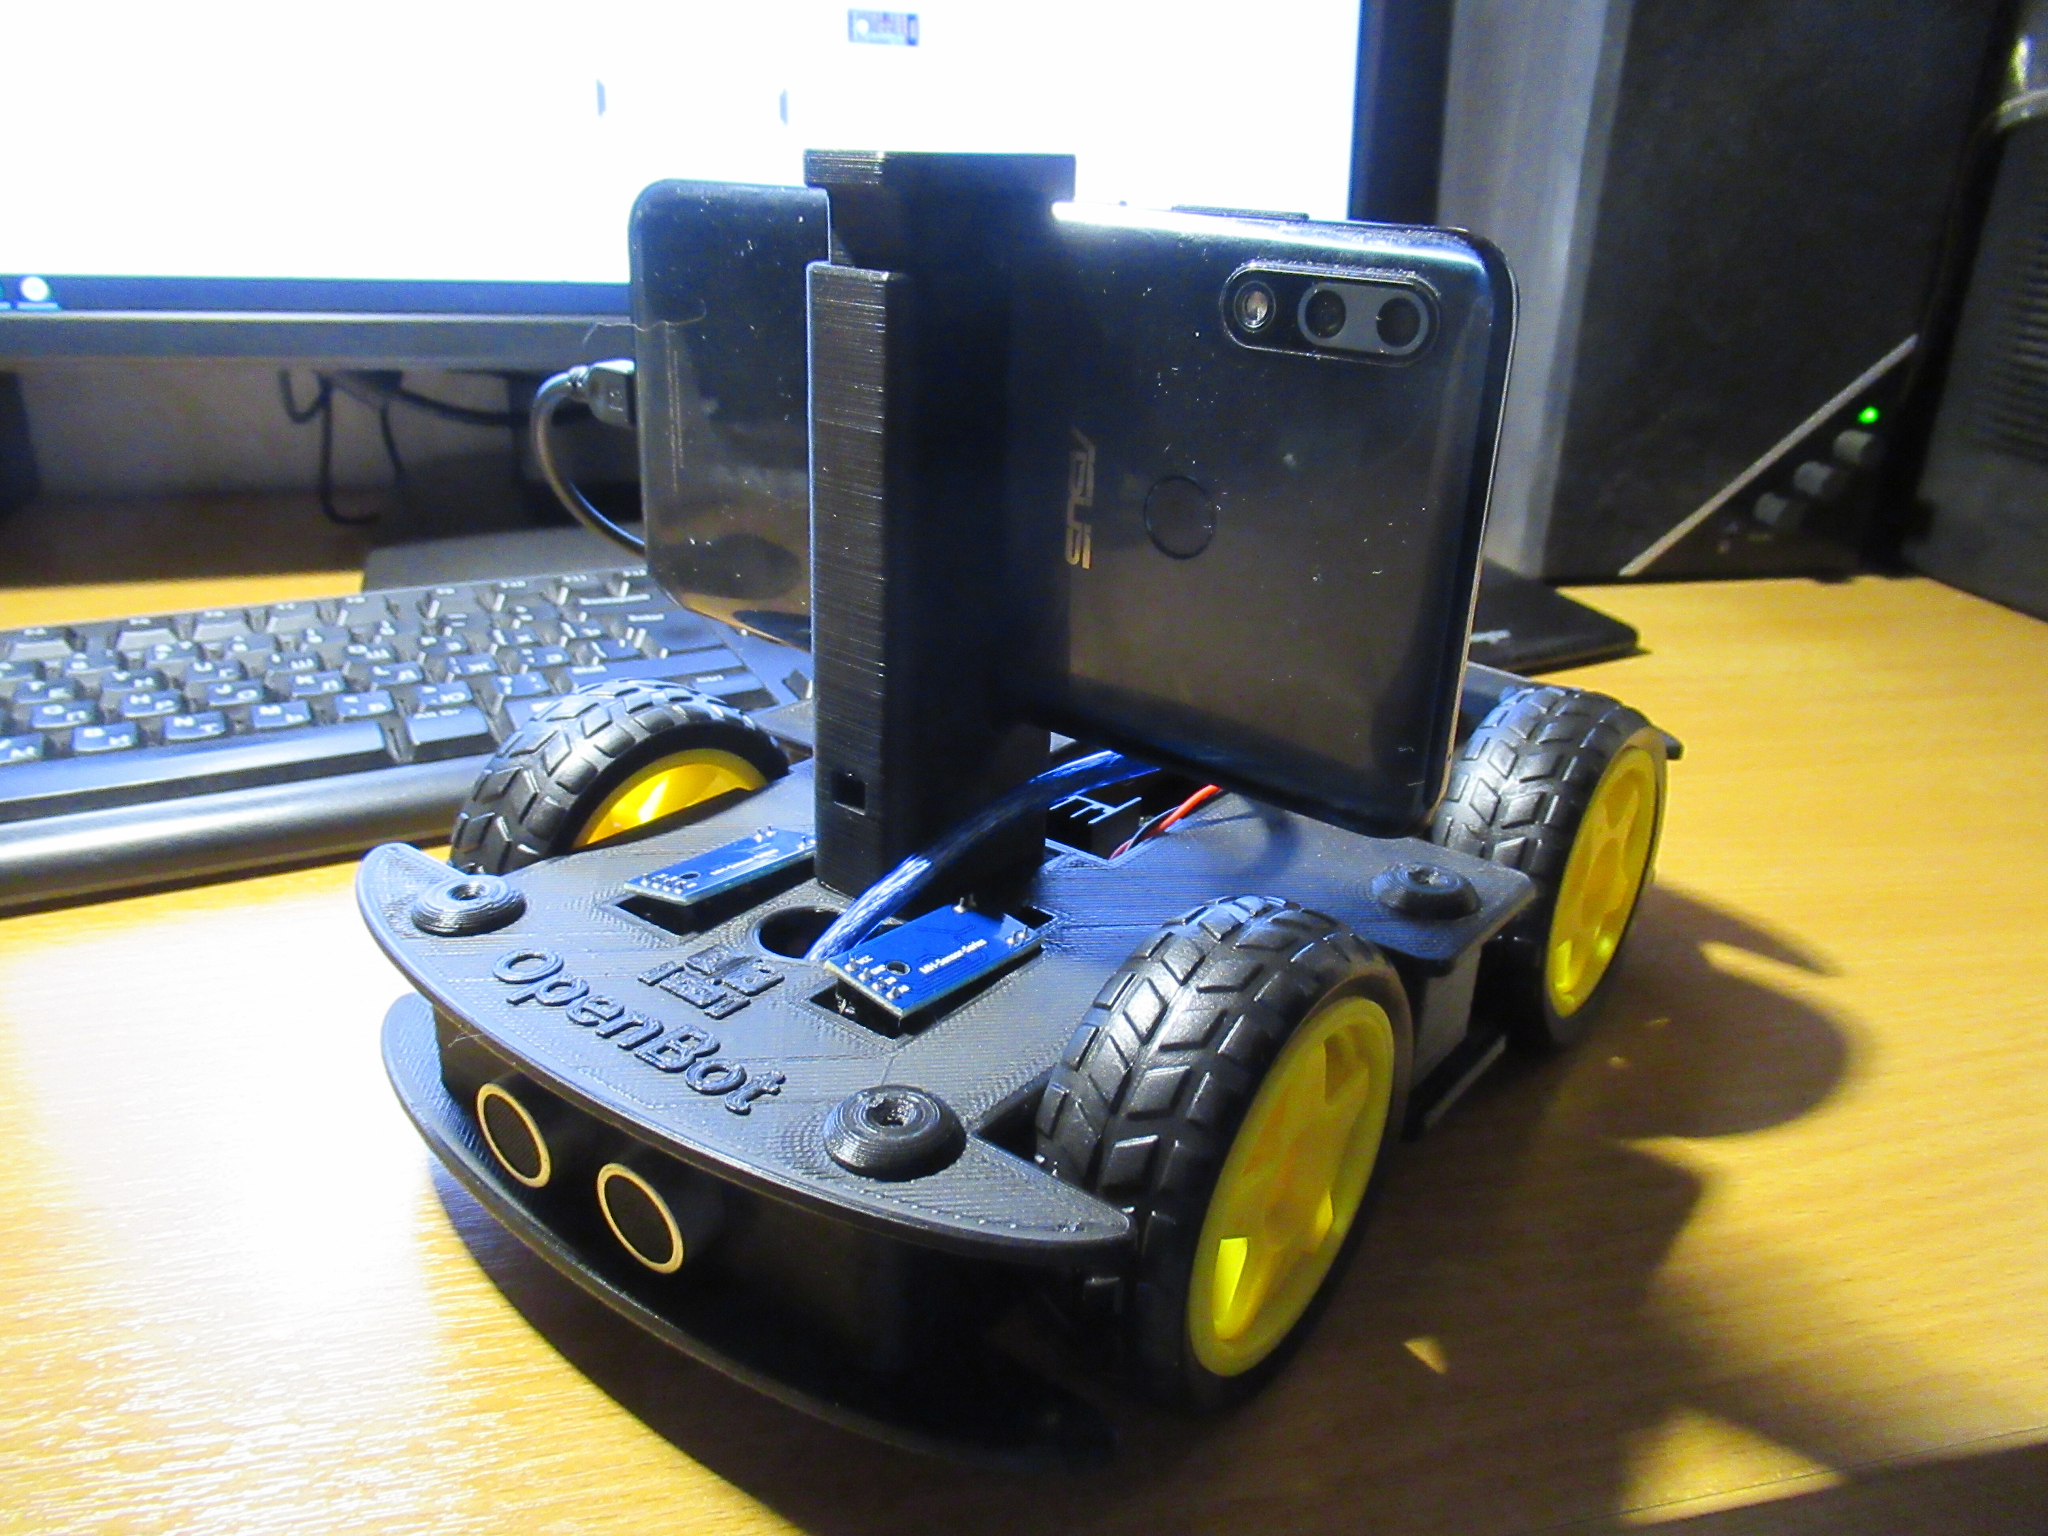
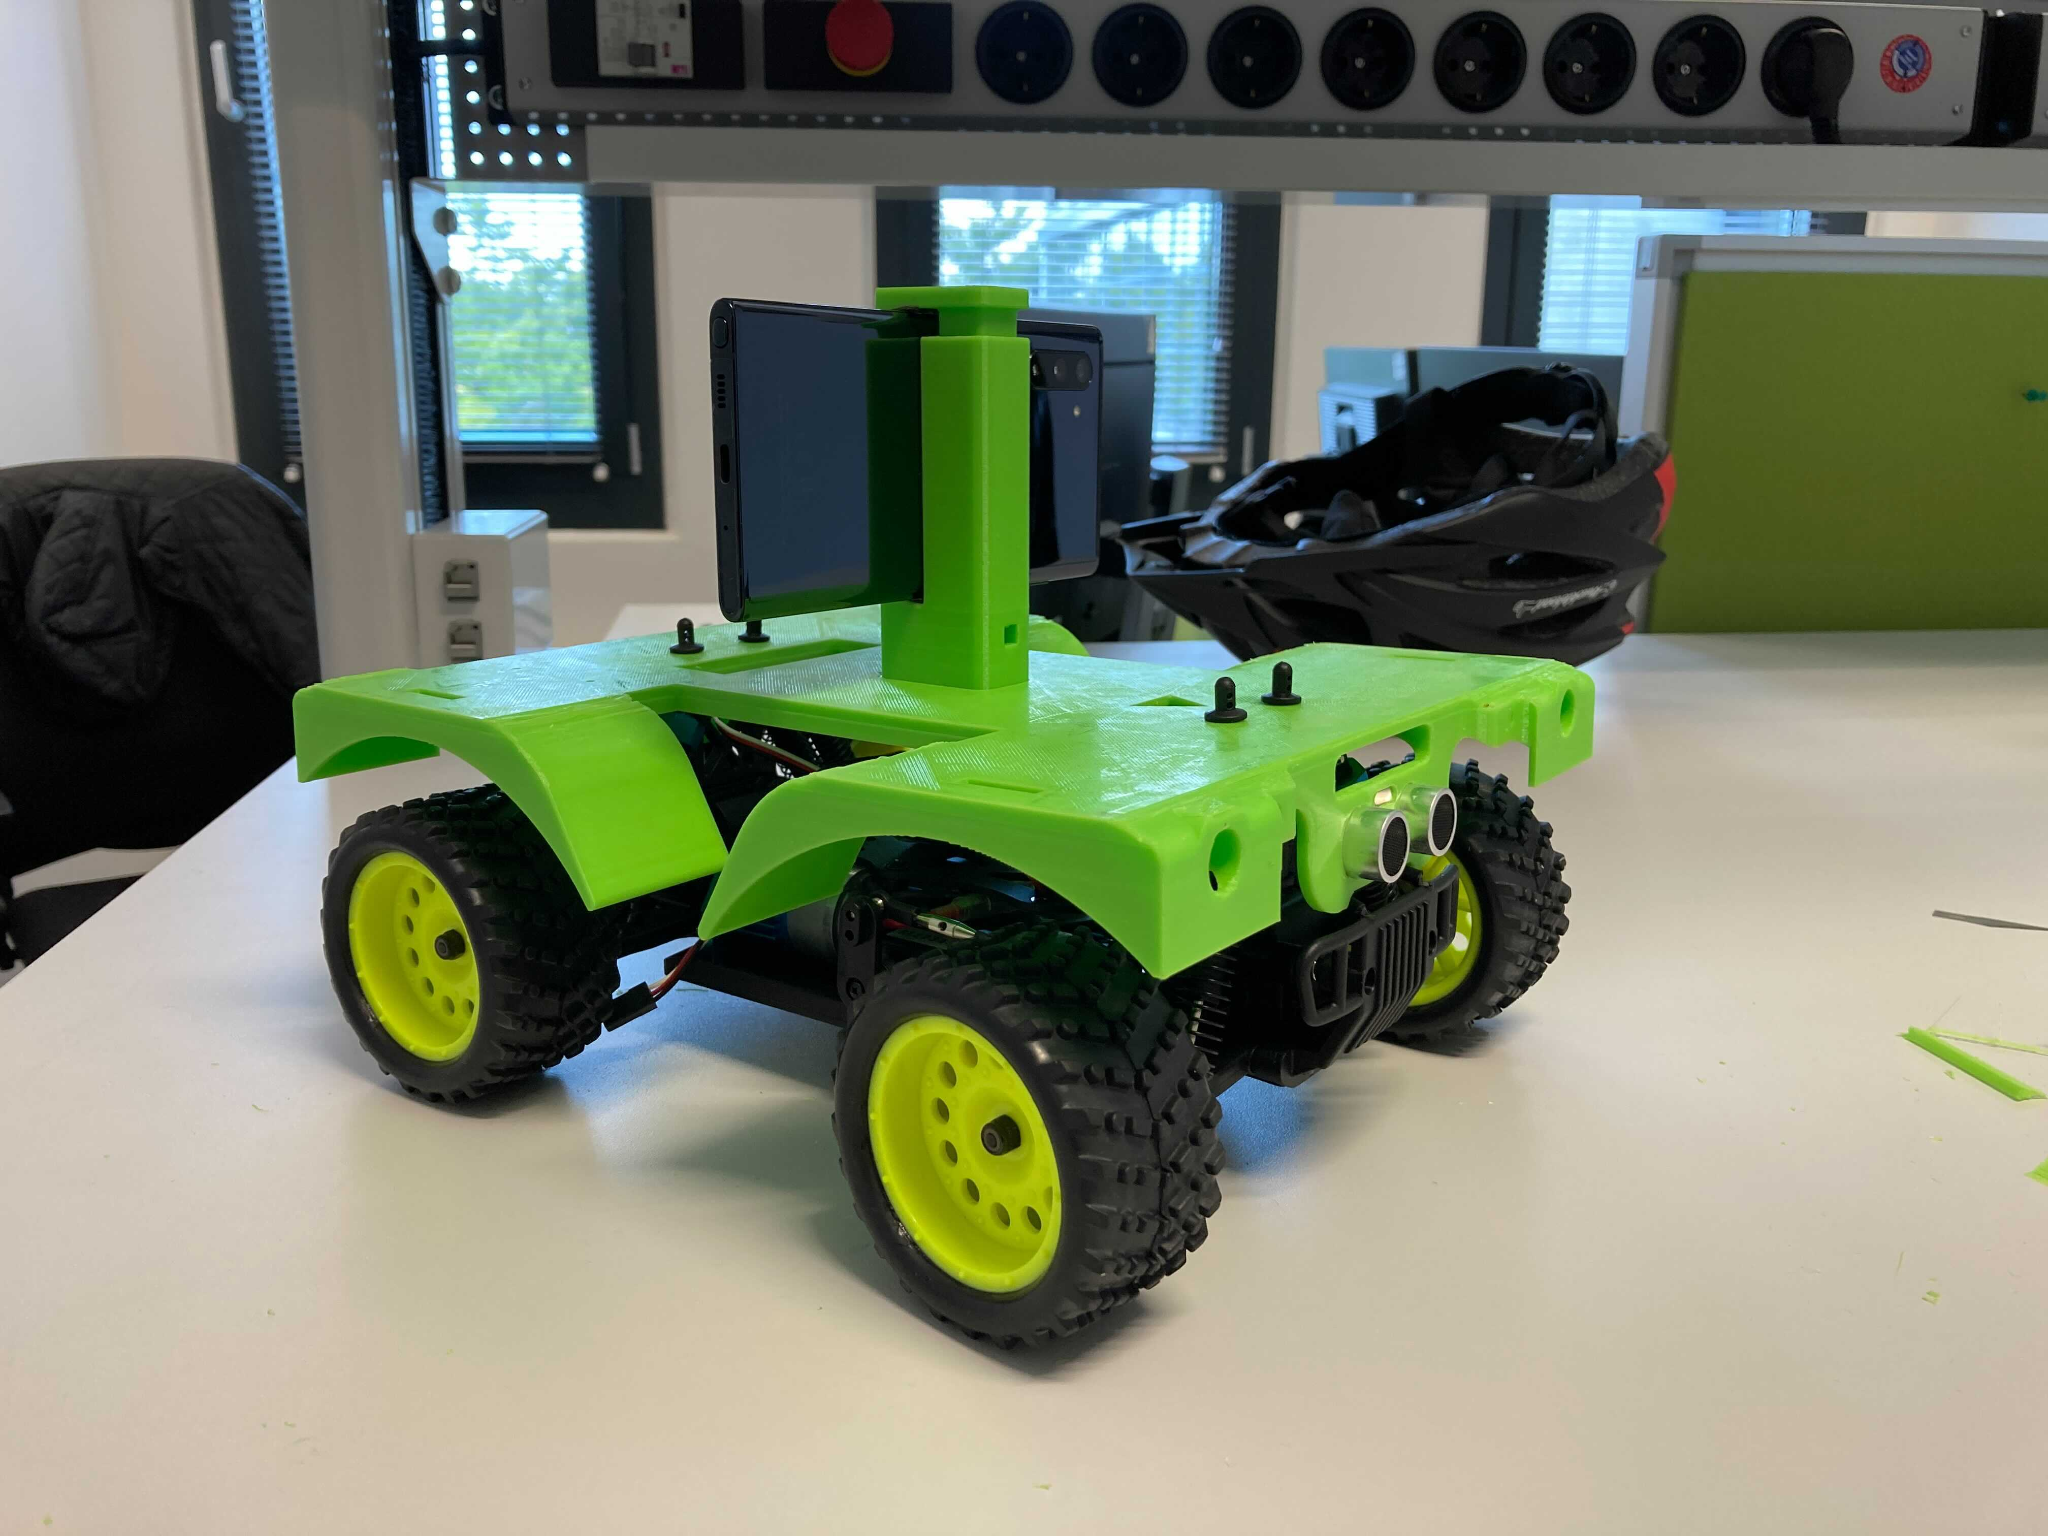
Community
👥 …and then the community started building.
community build
community build
community build
community build
community build
community build
community build
community build
community build
community build
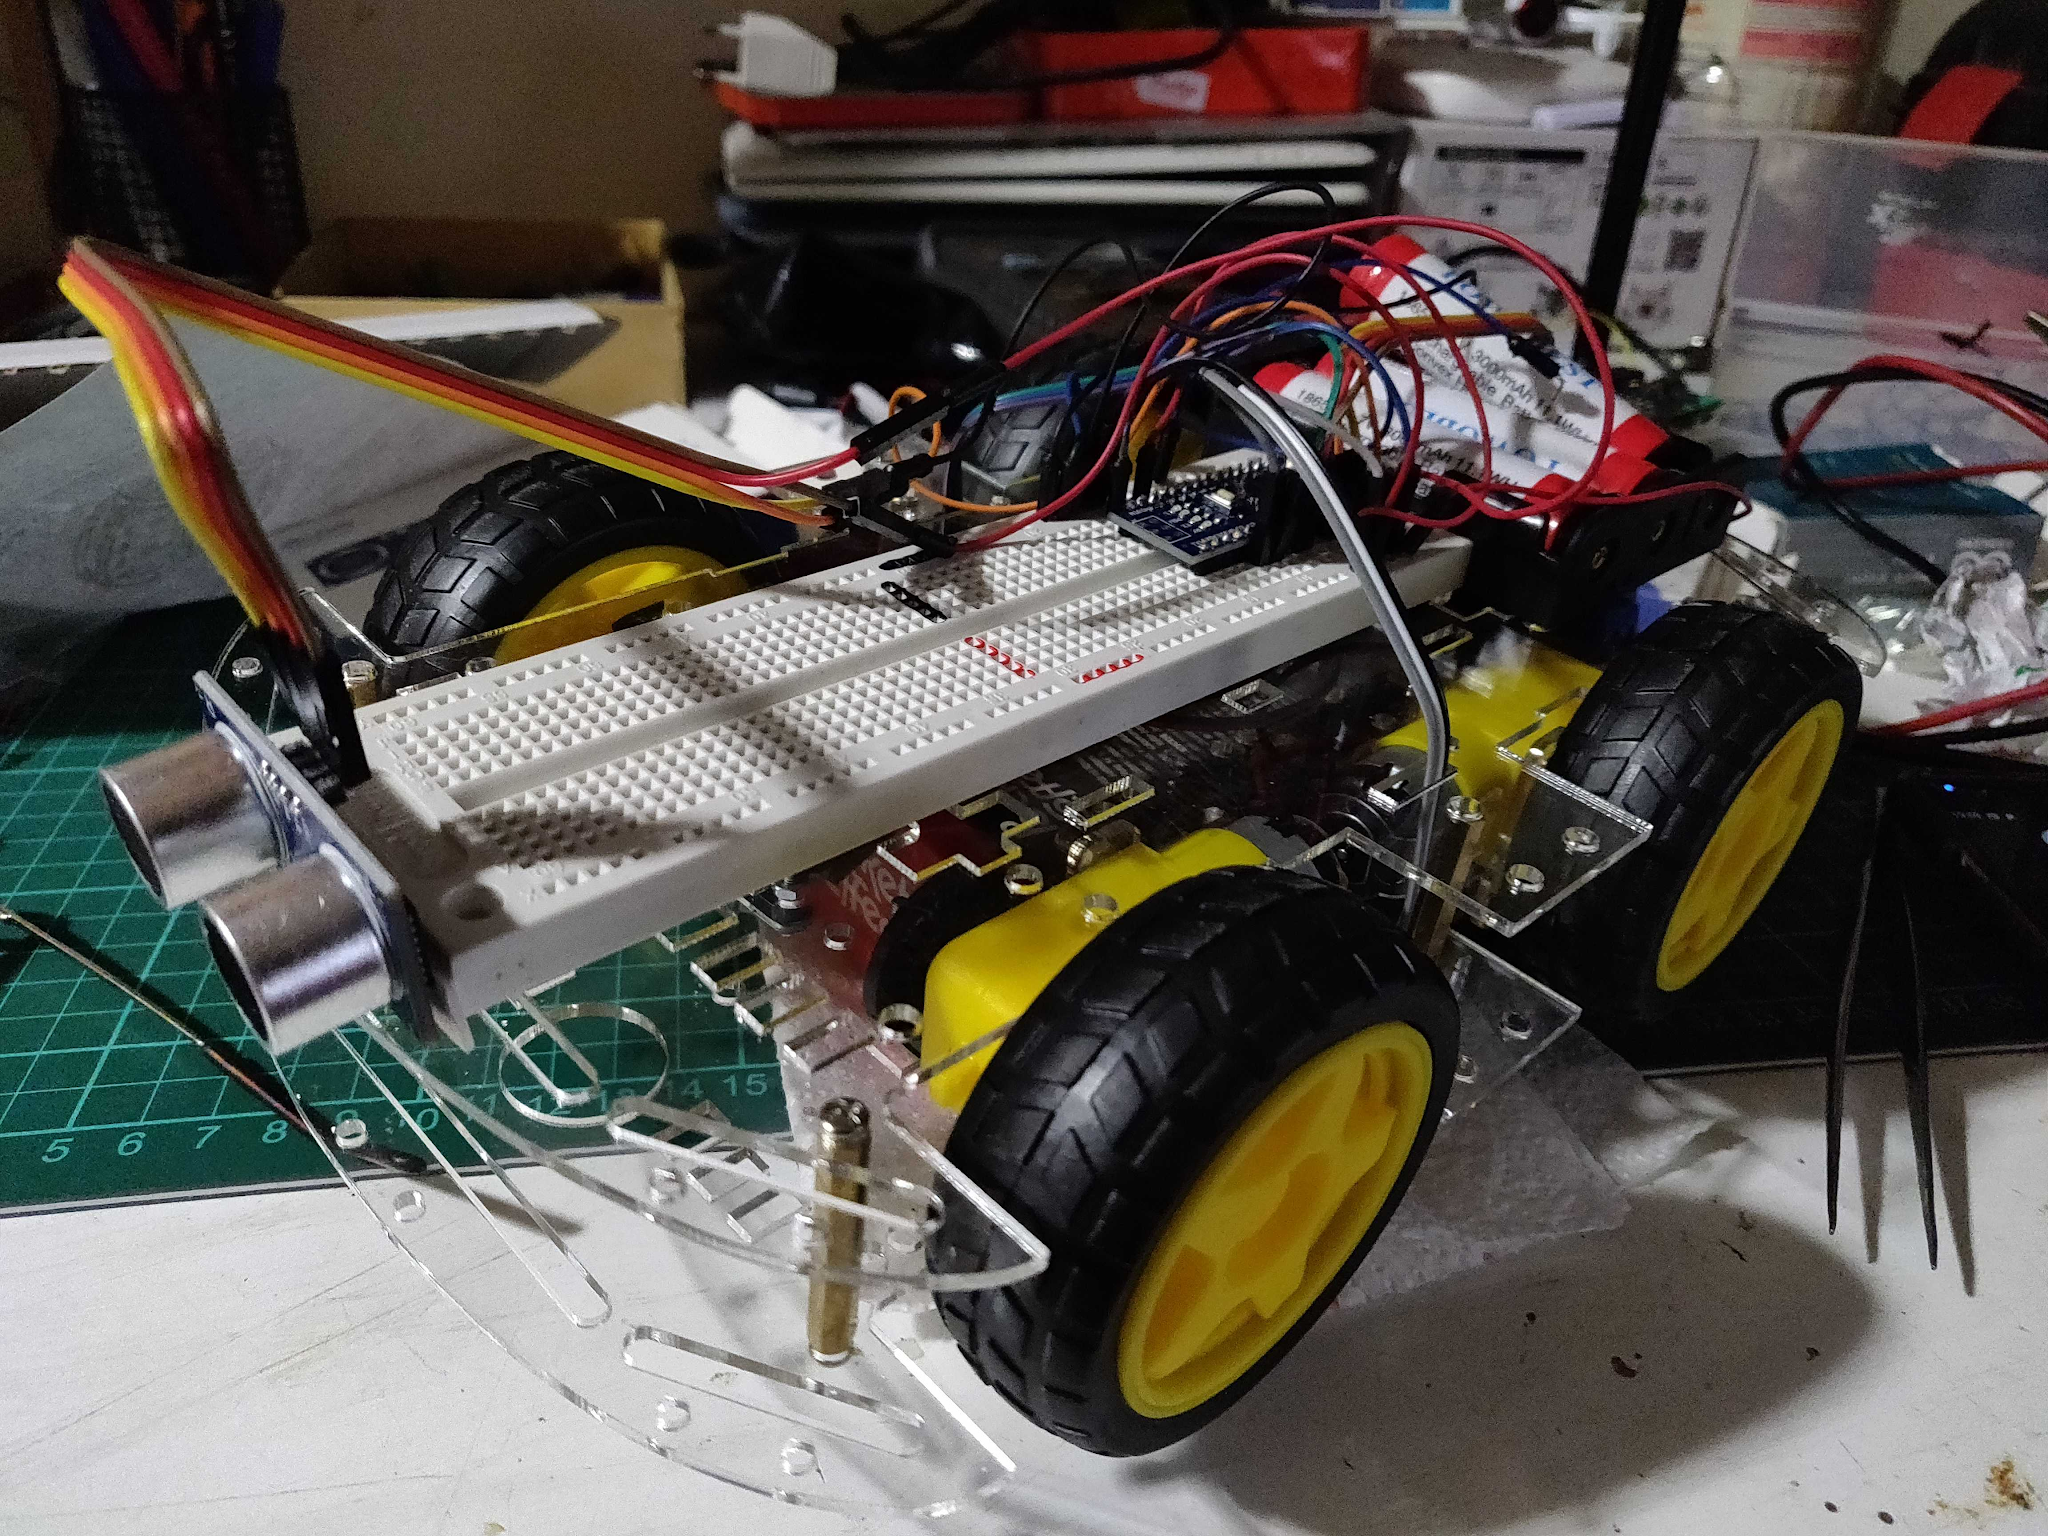
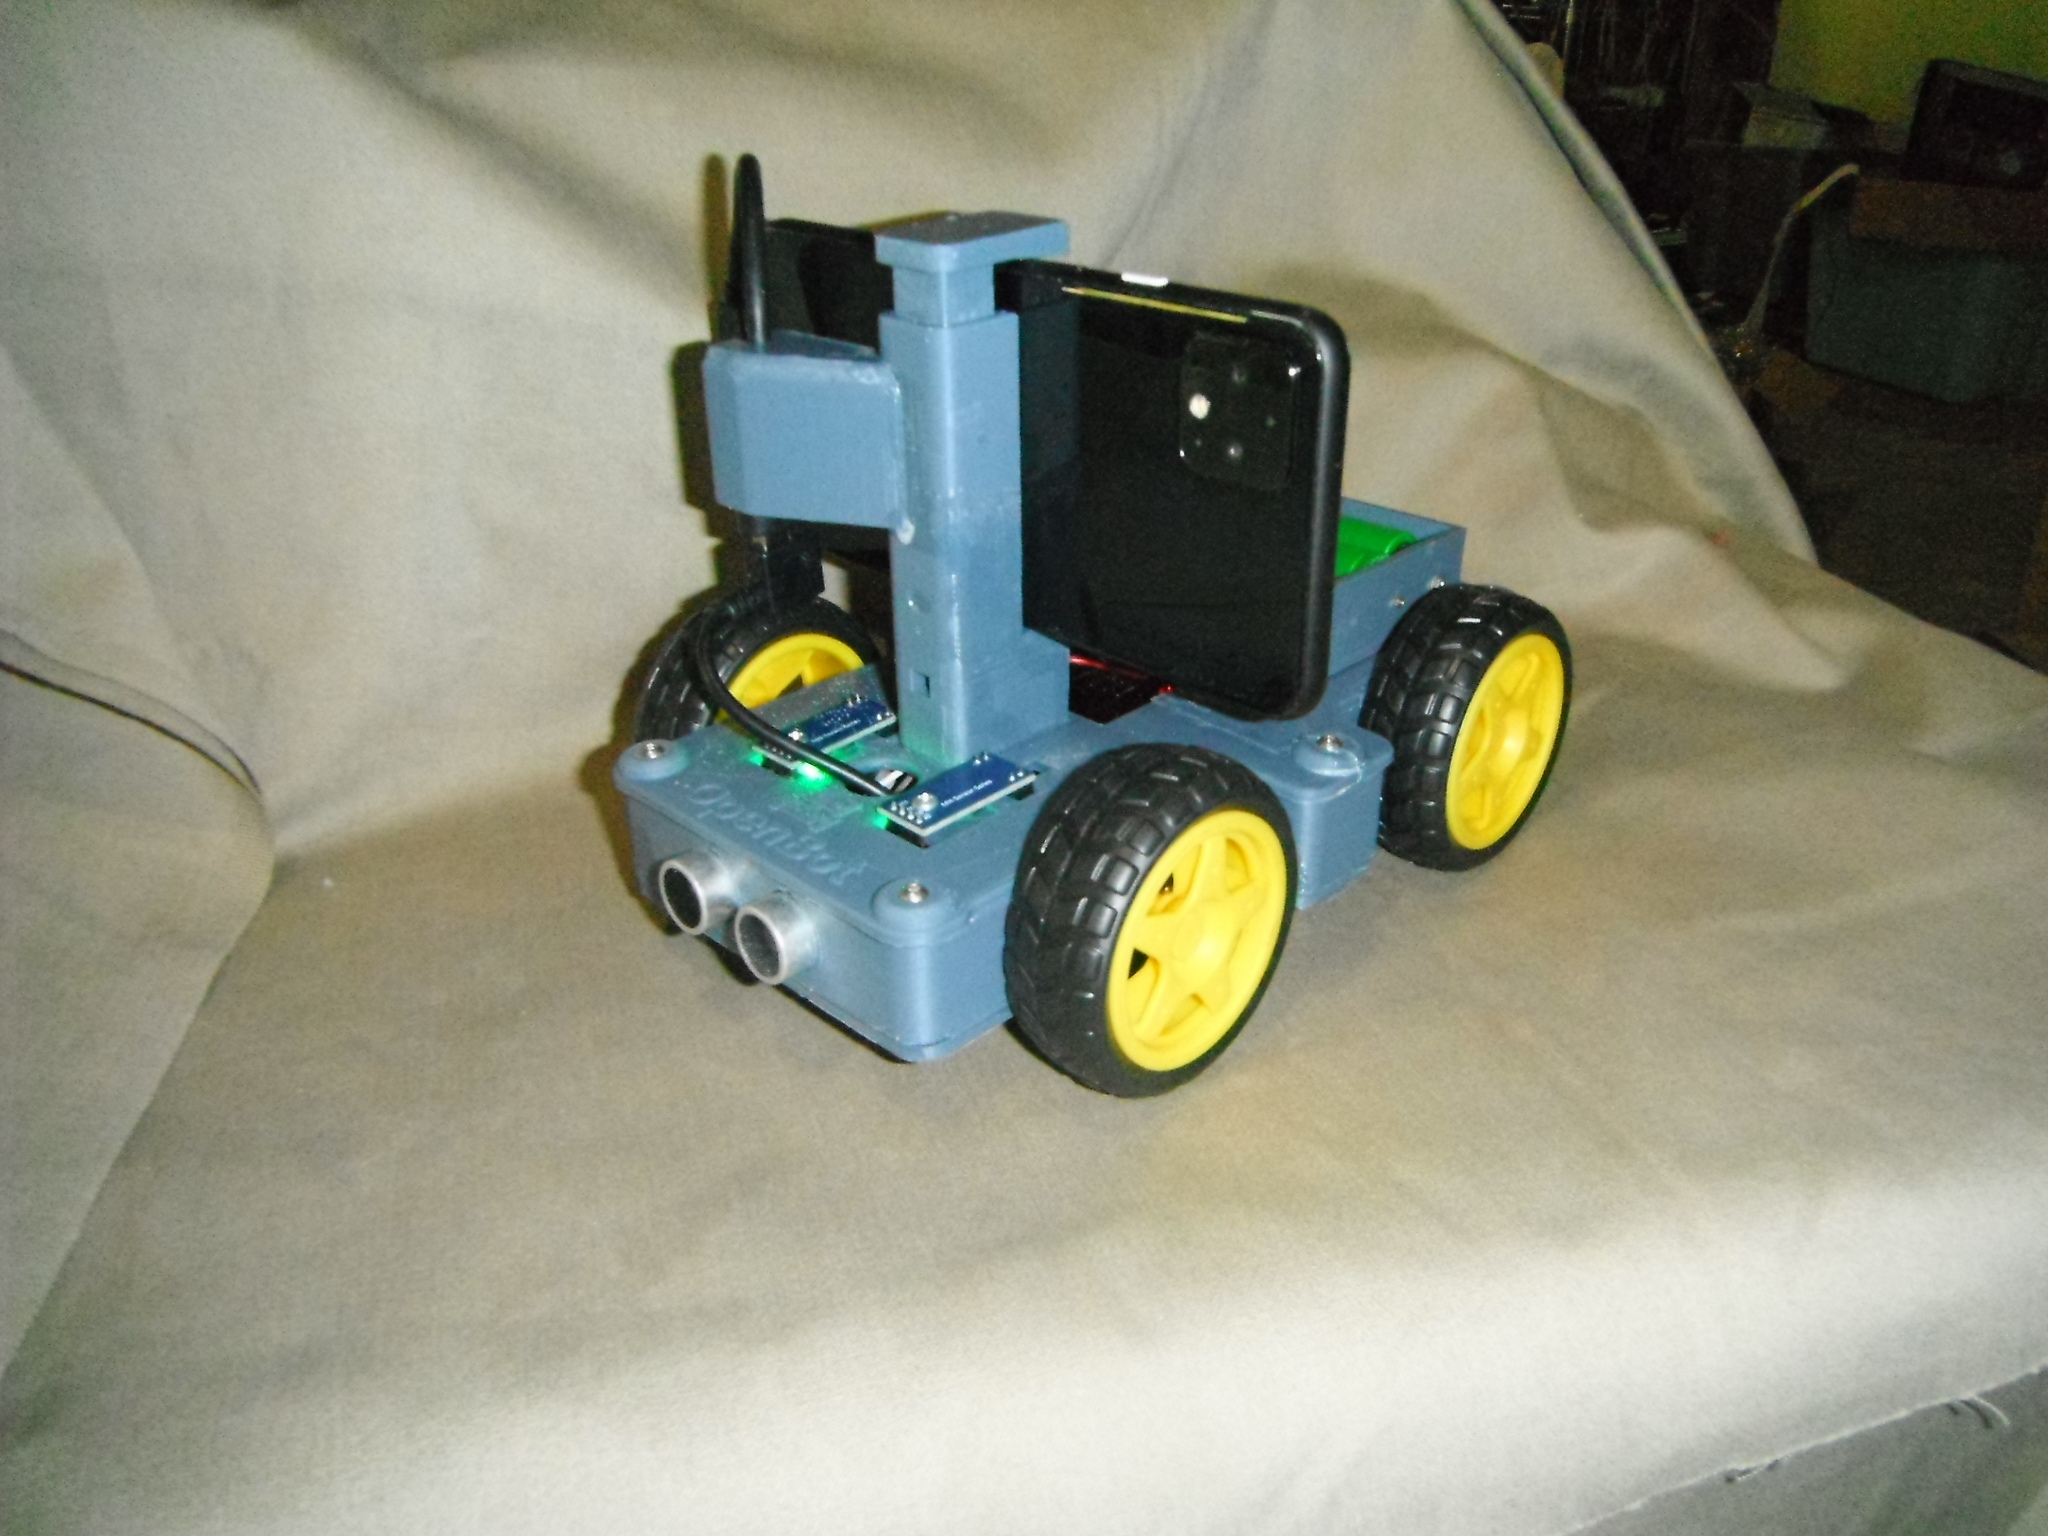
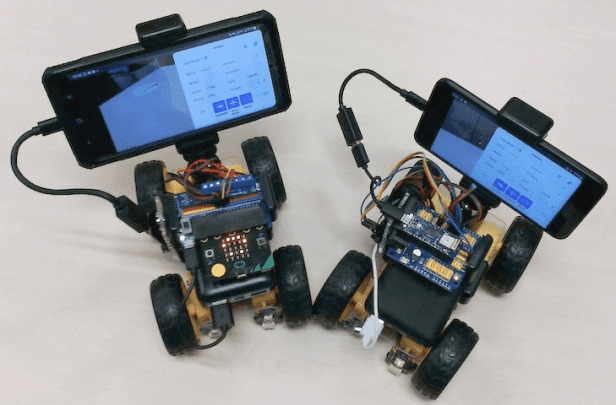
community build
Community · MTV
A Mars-rover-style OpenBot.

Multi-Terrain Vehicle · 6 wheels · rocker-bogie suspension · climbs stairs.

Community · OpenBot Yoda
Real-life Baby Yoda with AI.

By Manuel Ahumada · because open source.

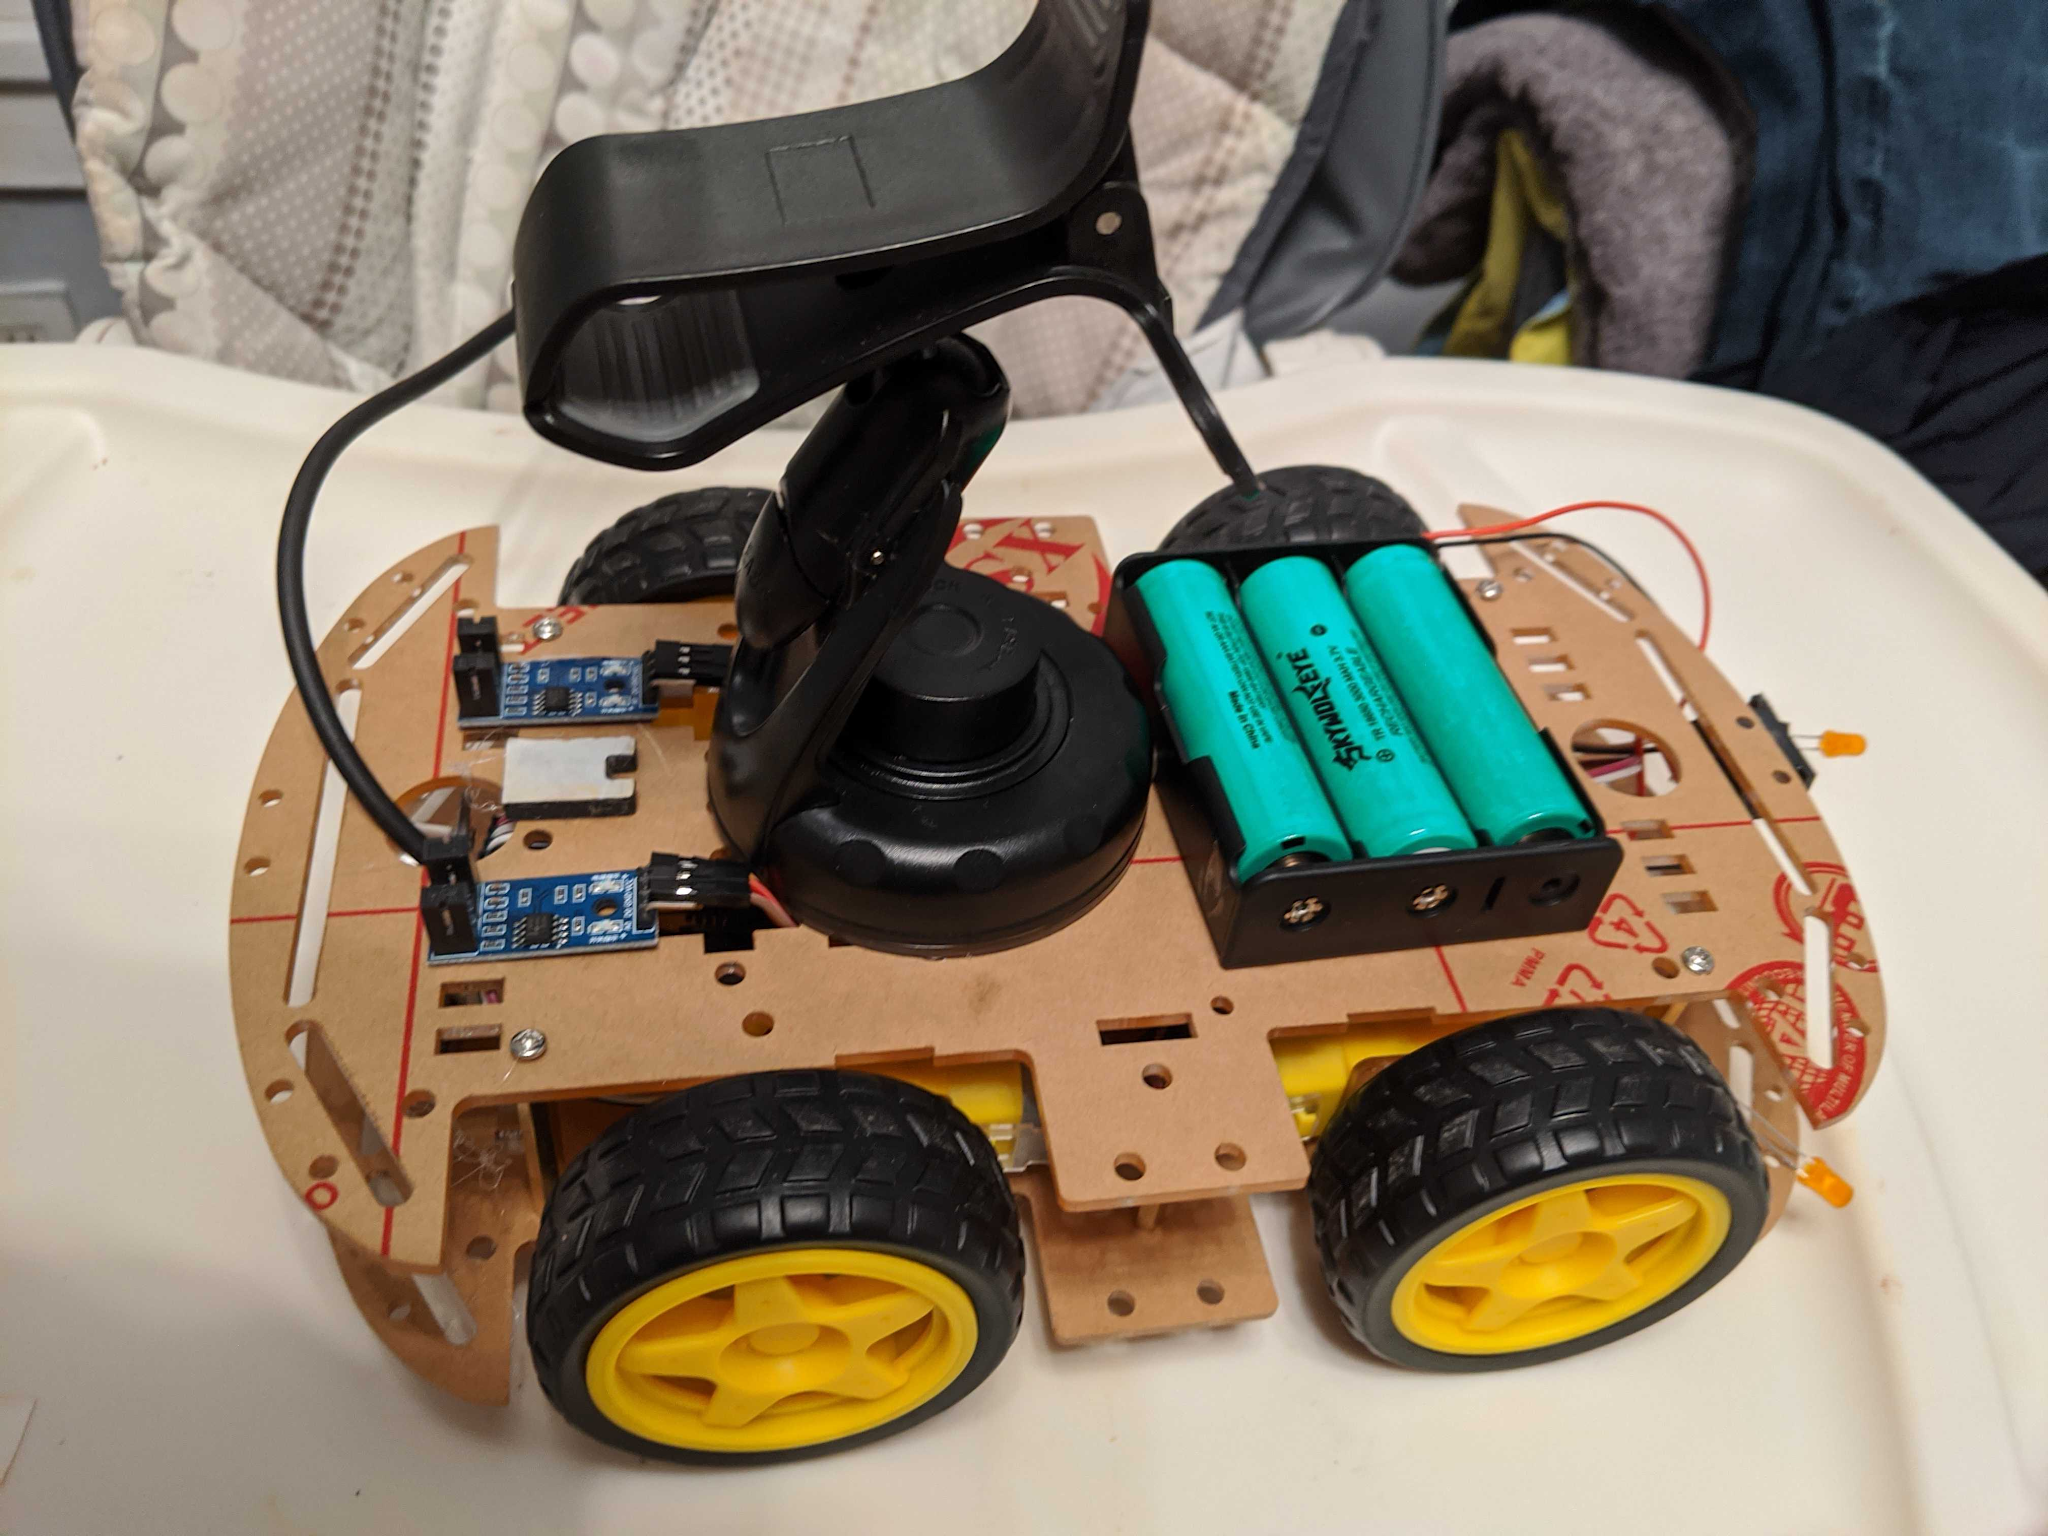
OpenBot for education
Autonomous driving on a track.

Students in Korea and Singapore training nav policies on the same body you'd build for $50.

🇰🇷 Korea
🇸🇬 Singapore

📺 Full instructional + playground tutorial playlists on the OpenBot YouTube channel.

OpenBot for education
Used in classrooms worldwide.
🇩🇪 Germany
🇮🇳 India
🇵🇹 Portugal
🇸🇬 Singapore
🇰🇷 South Korea
🇬🇧 UK
🇰🇬 Kyrgyzstan
…and more
OpenBot for education
Lots of videos on YouTube.
🎓 How to train your robot
📺 Lesson 04 · Motion
Everything's open source
openbot.org
openbot.org QR
📐 Hardware designs 💾 Code 📱 Apps 🎬 Videos 📝 Papers
Beyond OpenBot
Three things this taught me.
🔭
Follow curiosity
🛠
Build > consume
🤝
Use AI as a tool
Reality check
AI is in everyone's workflow now.
🎓
Students
Homework. Essays. Research. Lecture notes.
💻
Engineers
Copilot · Cursor · Claude Code. Most new code is AI-assisted.
✍️
Writers
Drafts. Edits. Brainstorms. Translations.
🔬
Researchers
Literature reviews. Data analysis. Code prototypes.

The question isn't if you use AI. It's how.

AI as Tool, Not Crutch
The AI interaction spectrum.
Do It Yourself
Roll up your sleeves.
No AI.
✓ Learning, edge cases, high stakes
⚠ Autopiloting through the hard parts
Debate
Stress-test your view
with AI.
✓ After forming your own view
⚠ Before you've thought at all
Delegate
Hand off the work
that won't sharpen you.
✓ Mechanical, repetitive work
⚠ Work that sharpens you

Don't default to delegate.
AI as tutor extends you. AI as crutch replaces you.

Stop Consuming. Start Building.
You don't prepare for the opportunity.
Projects are the preparation.
Build
Build what excites you.
Ignore prestige.
Stretch
Aim beyond your current skill.
That's where growth lives.
Compound
Pick projects that
unlock the next.

Curiosity today. Opportunity tomorrow.
Build now. Be ready always.

Final Thought
"The way to do great work
is to love what you do."

— Steve Jobs, Stanford Commencement, 2005

Get Ready. Start Now.
Get ready.

Follow your curiosity and passion. When the big opportunity comes, you won't have time to prepare — you need to be ready, and you are, because you've been building for years. Don't wait for a perfect plan.

Start now.
One More Thing
This presentation
was a project.
Before
PowerPoint. Keynote. Google Slides.
This time
Static HTML. Pure code. No slides app.
Built with Claude Code.
View online
QR code
Scan to open this presentation.

Stay curious. Find interesting projects. Never stop learning.